Uploaded May 2020 | Updated September 2026, 1 week ago
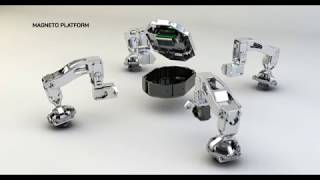
Magneto is a high degrees-of-freedom autonomous inspection robot that are capable of navigating complex ferrous environments. Their flexibility allows them to access visually occluded pockets, thereby improving inspection coverage and quality over human inspectors.
We are working collaboratively with Nexxis to commercialise Magneto.
For more information visit: https://research.csiro.au/robotics/paper-magneto-a-versatile-multi-limbed-inspection-robot/
Magneto is a high degrees-of-freedom autonomous inspection robot that are capable of navigating complex ferrous environments. Their flexibility allows them to access visually occluded pockets, thereby improving inspection coverage and quality over human inspectors.
We are working collaboratively with Nexxis to commercialise Magneto.
For more information visit: https://research.csiro.au/robotics/paper-magneto-a-versatile-multi-limbed-inspection-robot/