Uploaded February 2026 | Updated September 2026, 6 hours ago
This is the project video from Basil Clematide's bachelor's thesis on his interior space-mapping software. It was established in 2025 at the Bern University of Applied Sciences in Switzerland.
KubburScan is a Unity-based iOS application for real-time mapping of interior spaces. The aim of this work is to investigate the extent to which usable room measurements, object recognition, and 3D point clouds can be generated using LiDAR-enabled iPhone Pro devices. You can find more information at https://kubburscan.ch/.
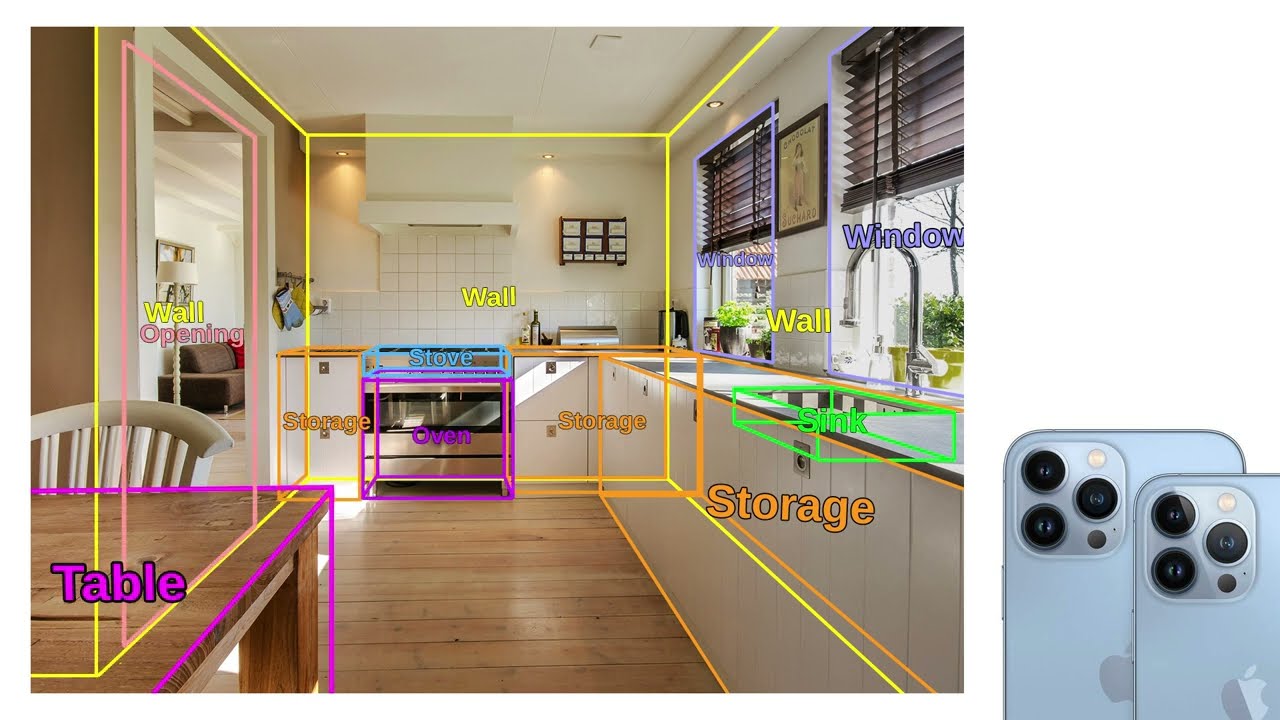
During the scan, the application detects and classifies structures such as walls, doors, and windows, as well as selected object classes, for example, chairs and tables. The results are visualized directly in the camera view as AR-anchored objects. Simultaneously, a point cloud of the scanned area is generated and exported upon completion.
Technically, KubburScan is based on ARKit and RoomPlan. RoomPlan supports sensor fusion and machine-learning-based recognition. Unity provides rendering and the user interface, including URP and VFX Graph.
A native iOS component is implemented to enable data exchange, as existing Unity AR packages do not provide sufficient access to ARSession and RoomPlan.
Video frames and point clouds are efficiently retrieved as binary data from native buffers via pull. Camera pose and detected objects are serialized as JSON and pushed to Unity. The point cloud is generated from the ARMeshAnchors, whose mesh vertices are extracted per frame, transformed into world coordinates, and deduplicated using a voxel grid. Export is performed as a PCD file and is made available via the iOS Share Sheet.
This is the project video from Basil Clematide's bachelor's thesis on his interior space-mapping software. It was established in 2025 at the Bern University of Applied Sciences in Switzerland.
KubburScan is a Unity-based iOS application for real-time mapping of interior spaces. The aim of this work is to investigate the extent to which usable room measurements, object recognition, and 3D point clouds can be generated using LiDAR-enabled iPhone Pro devices. You can find more information at https://kubburscan.ch/.
During the scan, the application detects and classifies structures such as walls, doors, and windows, as well as selected object classes, for example, chairs and tables. The results are visualized directly in the camera view as AR-anchored objects. Simultaneously, a point cloud of the scanned area is generated and exported upon completion.
Technically, KubburScan is based on ARKit and RoomPlan. RoomPlan supports sensor fusion and machine-learning-based recognition. Unity provides rendering and the user interface, including URP and VFX Graph.
A native iOS component is implemented to enable data exchange, as existing Unity AR packages do not provide sufficient access to ARSession and RoomPlan.
Video frames and point clouds are efficiently retrieved as binary data from native buffers via pull. Camera pose and detected objects are serialized as JSON and pushed to Unity. The point cloud is generated from the ARMeshAnchors, whose mesh vertices are extracted per frame, transformed into world coordinates, and deduplicated using a voxel grid. Export is performed as a PCD file and is made available via the iOS Share Sheet.