Uploaded June 2020 | Updated September 2026, 3 weeks ago
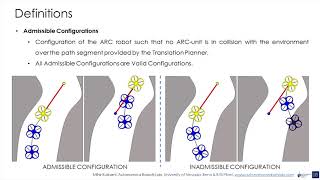
Abstract: This paper presents the design concept, modeling and motion planning solution for the aerial robotic chain. This design represents a configurable robotic system of systems, consisting of multi-linked micro aerial vehicles that simultaneously presents the ability to cross narrow sections, morph its shape, ferry significant payloads, offer the potential of distributed sensing and processing, and allow system extendability. We contribute an approach to address the motion planning problem of such a connected robotic system of systems, making full use of its reconfigurable nature, to find collision free paths in a fast manner despite the increased number of degrees of freedom. The presented approach exploits a library of aerial robotic chain configurations, optimized either for cross-section size or sensor coverage, alongside a probabilistic strategy to sample random shape configurations that may be needed to facilitate continued collision-free navigation. Evaluation studies in simulation involve traversal of constrained and obstacle-laden environments, having narrow corridors and cross sections.
Authors: Mihir Kulkarni, Huan Nguyen, Kostas Alexis
Affiliations:
1. M. Kulkarni: Mirla Institute of Technology and Autonomous Robots Lab, University of Nevada, Reno
2. Huan Nguyen, Kostas Alexis: Autonomous Robots Lab, University of Nevada, Reno
Abstract: This paper presents the design concept, modeling and motion planning solution for the aerial robotic chain. This design represents a configurable robotic system of systems, consisting of multi-linked micro aerial vehicles that simultaneously presents the ability to cross narrow sections, morph its shape, ferry significant payloads, offer the potential of distributed sensing and processing, and allow system extendability. We contribute an approach to address the motion planning problem of such a connected robotic system of systems, making full use of its reconfigurable nature, to find collision free paths in a fast manner despite the increased number of degrees of freedom. The presented approach exploits a library of aerial robotic chain configurations, optimized either for cross-section size or sensor coverage, alongside a probabilistic strategy to sample random shape configurations that may be needed to facilitate continued collision-free navigation. Evaluation studies in simulation involve traversal of constrained and obstacle-laden environments, having narrow corridors and cross sections.
Authors: Mihir Kulkarni, Huan Nguyen, Kostas Alexis
Affiliations:
1. M. Kulkarni: Mirla Institute of Technology and Autonomous Robots Lab, University of Nevada, Reno
2. Huan Nguyen, Kostas Alexis: Autonomous Robots Lab, University of Nevada, Reno