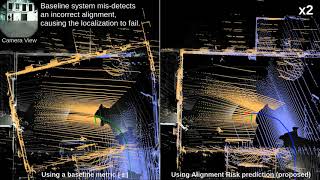
ICRA18 - Predicting Alignment Risk to Prevent Localization Failure @OxfordDynamicRobotSystemsGroup
ICRA18 - Predicting Alignment Risk to Prevent Localization Failure  @OxfordDynamicRobotSystemsGroup
Uploaded February 2018 | Updated September 2026, 3 weeks ago
robots.ox.ac.uk/~mobile/Papers/2018ICRA_nobili.pdf
ori.ox.ac.uk/drs
S. Nobili, G. Tinchev, and M. Fallon. ICRA 2018.
ICRA18 - Predicting Alignment Risk to Prevent Localization FailureRSS17 - Heterogeneous Sensor Fusion for Accurate State Estimation of Dynamic Legged RobotsSiLVR: Scalable Lidar-Visual Reconstruction with Neural RadianceFields for Robotic InspectionLearning and Deploying Robust Locomotion Policies with Minimal Dynamics RandomizationRA-L/ICRA 2021 - Unified Landmark Tracking for Odometry [Finalist ICRA Best Student Paper]Ensuring Safe Visual Teach and Repeat Legged Navigation using Local World Representations[Presentation] Elastic and Efficient LiDAR Reconstruction for Large-Scale Exploration TasksPlane Seg on ANYmal (Simulation)RA-L/IROS 2019 - Robust Legged Robot State Estimation Using Factor Graph OptimizationLearning Low-Frequency Motion Control for Robust and Dynamic Robot LocomotionSapling-NeRF: Geo-Localised Sapling Reconstruction in Forests for Ecological MonitoringSafe Visual Navigation in an Underground Mine
Oxford Dynamic Robot Systems Group |

ICRA18 - Predicting Alignment Risk to Prevent Localization Failure

SHARE TO X SHARE TO REDDIT SHARE TO FACEBOOK WALLPAPER