Uploaded March 2024 | Updated September 2026, 3 weeks ago
Accepted to ICRA 2024
Website: ori-drs.github.io/projects/silvr
Pre-print: arxiv.org/abs/2403.06877
[Abstract]
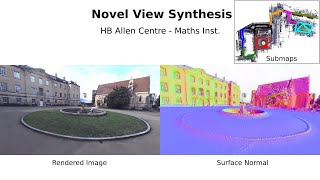
We present a neural-field-based large-scale reconstruction system that fuses lidar and vision data to generate high-quality reconstructions that are geometrically accurate and capture photo-realistic textures. This system adapts the state-of-the-art neural radiance field (NeRF) representation to also incorporate lidar data which adds strong geometric constraints on the depth and surface normals. We exploit the trajectory from a real-time lidar SLAM system to bootstrap a Structure-from-Motion (SfM) procedure to both significantly reduce the computation time and to provide metric scale which is crucial for lidar depth loss. We use submapping to scale the system to large-scale environments captured over long trajectories. We demonstrate the reconstruction system with data from a multi-camera, lidar sensor suite onboard a legged robot, hand-held while scanning building scenes for 600 metres, and onboard an aerial robot surveying a multi-storey mock disaster site-building.
Authors: Yifu Tao , Yash Bhalgat, Lanke Frank Tarimo Fu, Matias Mattamala , Nived Chebrolu, Maurice Fallon
Accepted to ICRA 2024
Website: ori-drs.github.io/projects/silvr
Pre-print: arxiv.org/abs/2403.06877
[Abstract]
We present a neural-field-based large-scale reconstruction system that fuses lidar and vision data to generate high-quality reconstructions that are geometrically accurate and capture photo-realistic textures. This system adapts the state-of-the-art neural radiance field (NeRF) representation to also incorporate lidar data which adds strong geometric constraints on the depth and surface normals. We exploit the trajectory from a real-time lidar SLAM system to bootstrap a Structure-from-Motion (SfM) procedure to both significantly reduce the computation time and to provide metric scale which is crucial for lidar depth loss. We use submapping to scale the system to large-scale environments captured over long trajectories. We demonstrate the reconstruction system with data from a multi-camera, lidar sensor suite onboard a legged robot, hand-held while scanning building scenes for 600 metres, and onboard an aerial robot surveying a multi-storey mock disaster site-building.
Authors: Yifu Tao , Yash Bhalgat, Lanke Frank Tarimo Fu, Matias Mattamala , Nived Chebrolu, Maurice Fallon