Uploaded January 2026 | Updated September 2026, 3 hours ago
Calibrating the measurement using slow-mo video and BLDC motor fundamentals …
↓↓↓ Complete description, time index and links below ↓↓↓
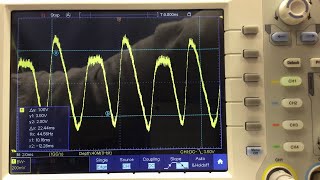
In the previous video we’ve used the analog comparator of the ATmega4809 to measure the frequency of the sinusoidal current fluctuations and thus the RPM. But we weren’t sure if those measurements wee correct. It’s time to rectify that.
We start by taking some slow-motion video of the propeller to determine its RPM. Then we dive into some brushless permanent magnet motor fundamentals. With both we adjust our code to get accurate RPM measurements.
00:00 Intro – let’s verify our RPM measurement
01:07 Measuring – prop’s RPM with slow-mo video
07:11 Results – we’re off a factor of about 1.6
09:10 Theory – brushless permanent magnet motors
14:31 Motor – the stator of our motor has twelve coils
16:13 Code – changed to 48 edges per rotation
17:59 Test – all measurements are matching nicely
19:21 Wrap-up – should have done that sooner, bye
Full Fly-by-Wire Electric Outboard youtube.com/playlist?list=PLwq-2MnM58FKvpYgFXgNCjlKo14L0KI16
Full Fly-by-Wire Electric Outboard (27): Housekeeping (2) youtu.be/sxmy_BU-NdY
Full Fly-by-Wire Electric Outboard (26): RPM Measurement via Motor Current (2) youtu.be/LOpRj7fxl8E
Full Fly-by-Wire Electric Outboard (29): Detection of Motor Driver Beep Codes (1) youtu.be/nUMtIUAyg8g
#flybywire #electricoutboard #haswing #trollingmotor #outboardmotor #outboard #robertssmorgasbord
Calibrating the measurement using slow-mo video and BLDC motor fundamentals …
↓↓↓ Complete description, time index and links below ↓↓↓
In the previous video we’ve used the analog comparator of the ATmega4809 to measure the frequency of the sinusoidal current fluctuations and thus the RPM. But we weren’t sure if those measurements wee correct. It’s time to rectify that.
We start by taking some slow-motion video of the propeller to determine its RPM. Then we dive into some brushless permanent magnet motor fundamentals. With both we adjust our code to get accurate RPM measurements.
00:00 Intro – let’s verify our RPM measurement
01:07 Measuring – prop’s RPM with slow-mo video
07:11 Results – we’re off a factor of about 1.6
09:10 Theory – brushless permanent magnet motors
14:31 Motor – the stator of our motor has twelve coils
16:13 Code – changed to 48 edges per rotation
17:59 Test – all measurements are matching nicely
19:21 Wrap-up – should have done that sooner, bye
Full Fly-by-Wire Electric Outboard youtube.com/playlist?list=PLwq-2MnM58FKvpYgFXgNCjlKo14L0KI16
Full Fly-by-Wire Electric Outboard (27): Housekeeping (2) youtu.be/sxmy_BU-NdY
Full Fly-by-Wire Electric Outboard (26): RPM Measurement via Motor Current (2) youtu.be/LOpRj7fxl8E
Full Fly-by-Wire Electric Outboard (29): Detection of Motor Driver Beep Codes (1) youtu.be/nUMtIUAyg8g
#flybywire #electricoutboard #haswing #trollingmotor #outboardmotor #outboard #robertssmorgasbord