Uploaded July 2021 | Updated September 2026, 3 days ago
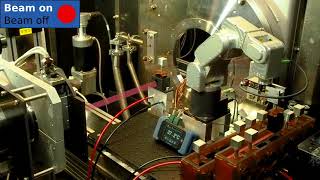
Rotating Joint 6 beyond the ±180° has always been possible with the Meca500 R3, but it was limited to Joint-move-commands. With this new firmware, both point-to-point and linear commands can now be used outside of this limit. Apart from the benefit of no longer being limited in Cartesian space and requiring switching to Joint commands, new applications are now easier to implement directly with the Meca500.
In terms of application benefits: It’s now easier to use the Meca500 for dispensing, capping, testing, and any other application that requires moving Joint 6 beyond the previous default limits. Of course, we have now introduced a new configuration parameter, to specify the desired turn for joint 6. By default, the automatic configuration for this turn parameter is disabled, please read the programming manual before enabling it.
Firmware 8.4 full features & benefits: mecademic.com/en/mecademic-robotics-releases-new-firmware-for-its-meca500-robot
---
About this robot: The Meca500 is the world's smallest, most precise and compact industrial robotic arm. To learn more: mecademic.com
Rotating Joint 6 beyond the ±180° has always been possible with the Meca500 R3, but it was limited to Joint-move-commands. With this new firmware, both point-to-point and linear commands can now be used outside of this limit. Apart from the benefit of no longer being limited in Cartesian space and requiring switching to Joint commands, new applications are now easier to implement directly with the Meca500.
In terms of application benefits: It’s now easier to use the Meca500 for dispensing, capping, testing, and any other application that requires moving Joint 6 beyond the previous default limits. Of course, we have now introduced a new configuration parameter, to specify the desired turn for joint 6. By default, the automatic configuration for this turn parameter is disabled, please read the programming manual before enabling it.
Firmware 8.4 full features & benefits: mecademic.com/en/mecademic-robotics-releases-new-firmware-for-its-meca500-robot
---
About this robot: The Meca500 is the world's smallest, most precise and compact industrial robotic arm. To learn more: mecademic.com