Uploaded February 2020 | Updated September 2026, 39 minutes ago
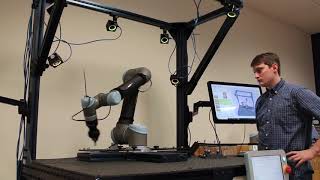
We created a G-code toolpath in Autodesk Fusion 360 based on the UR logo pattern and imported it into Polyscope using the new Remote TCP & Toolpath URCap. It took about 15 minutes to create the toolpath and 30 minutes to set up the program on the robot.
In this demo:
* Robot: UR3e (universal-robots.com/products/ur3-robot)
* Software: Remote TCP & Toolpath URCap in Polyscope 5.6 (universal-robots.com/how-tos-and-faqs/how-to/ur-how-tos/remote-tcp-toolpath-urcap-instructional-videos-63120)
* End-effector: Fancort Dispense Kit (universal-robots.com/plus/process-end-effectors/fancort-dispense-kit)
* Other Accessory: Millibar Manual Tool Changer (universal-robots.com/plus/accessories/millibar-manual-tool-changer)
We created a G-code toolpath in Autodesk Fusion 360 based on the UR logo pattern and imported it into Polyscope using the new Remote TCP & Toolpath URCap. It took about 15 minutes to create the toolpath and 30 minutes to set up the program on the robot.
In this demo:
* Robot: UR3e (universal-robots.com/products/ur3-robot)
* Software: Remote TCP & Toolpath URCap in Polyscope 5.6 (universal-robots.com/how-tos-and-faqs/how-to/ur-how-tos/remote-tcp-toolpath-urcap-instructional-videos-63120)
* End-effector: Fancort Dispense Kit (universal-robots.com/plus/process-end-effectors/fancort-dispense-kit)
* Other Accessory: Millibar Manual Tool Changer (universal-robots.com/plus/accessories/millibar-manual-tool-changer)