Uploaded February 2020 | Updated September 2026, 5 hours ago
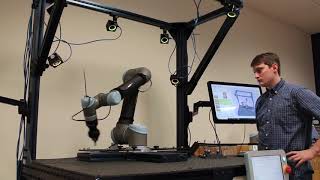
We configured the dispense head, fixed relative to the robot base, as a Remote TCP using the Remote TCP URCap in Polyscope 5.5. The robot motion was programmed using Remote TCP MoveP commands. The robot was able to move the part at a constant speed relative to the dispense head.
What we used in this demo:
* Robot: UR10e (universal-robots.com/products/ur10-robot)
* Software: Remote TCP URCap in Polyscope 5.5 (universal-robots.com/how-tos-and-faqs/how-to/ur-how-tos/remote-tcp-example-sheet-metal-deburring-54588)
* End-effector: Robotiq EPick (universal-robots.com/plus/handling-grippers/epick)
* Other Accessory: Fancort Dispense Kit (universal-robots.com/plus/process-end-effectors/fancort-dispense-kit)
We configured the dispense head, fixed relative to the robot base, as a Remote TCP using the Remote TCP URCap in Polyscope 5.5. The robot motion was programmed using Remote TCP MoveP commands. The robot was able to move the part at a constant speed relative to the dispense head.
What we used in this demo:
* Robot: UR10e (universal-robots.com/products/ur10-robot)
* Software: Remote TCP URCap in Polyscope 5.5 (universal-robots.com/how-tos-and-faqs/how-to/ur-how-tos/remote-tcp-example-sheet-metal-deburring-54588)
* End-effector: Robotiq EPick (universal-robots.com/plus/handling-grippers/epick)
* Other Accessory: Fancort Dispense Kit (universal-robots.com/plus/process-end-effectors/fancort-dispense-kit)