Uploaded January 2019 | Updated September 2026, 1 week ago
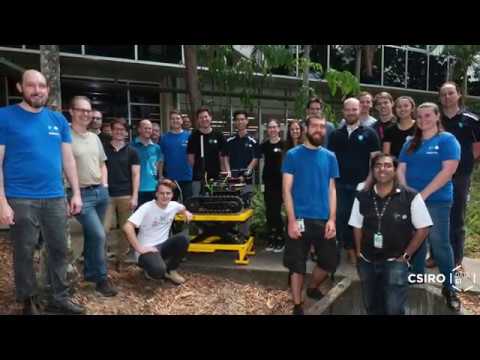
CSIRO's Robotics and Autonomous Systems group is competing in the DARPA SubT Challenge. This video depicts a sample of our submission for the STIX (SubT Integration Exercise) qualification. This shows a tracked platform (one of many modalities to be used in the challenge) with our custom perception payload autonomously navigating across rough ground and through a subterranean environment, whilst autonomously detecting and classifying objects.
Learn more about our participation in the DARPA SubT Challenge here:
https://research.csiro.au/robotics/we-qualified-darpa-subt-challenge-csiro-december-update/
This research was developed with funding from the Defense Advanced Research Projects Agency (DARPA). The views, opinions and/or findings expressed are those of the author and should not be interpreted as representing the official views or policies of the Department of Defense or the U.S. Government.
Music:
Transportation by Audionautix is licensed under a Creative Commons Attribution license (creativecommons.org/licenses/by/4.0/)
Artist: audionautix.com
CSIRO's Robotics and Autonomous Systems group is competing in the DARPA SubT Challenge. This video depicts a sample of our submission for the STIX (SubT Integration Exercise) qualification. This shows a tracked platform (one of many modalities to be used in the challenge) with our custom perception payload autonomously navigating across rough ground and through a subterranean environment, whilst autonomously detecting and classifying objects.
Learn more about our participation in the DARPA SubT Challenge here:
https://research.csiro.au/robotics/we-qualified-darpa-subt-challenge-csiro-december-update/
This research was developed with funding from the Defense Advanced Research Projects Agency (DARPA). The views, opinions and/or findings expressed are those of the author and should not be interpreted as representing the official views or policies of the Department of Defense or the U.S. Government.
Music:
Transportation by Audionautix is licensed under a Creative Commons Attribution license (creativecommons.org/licenses/by/4.0/)
Artist: audionautix.com