Uploaded October 2014 | Updated September 2026, 1 week ago
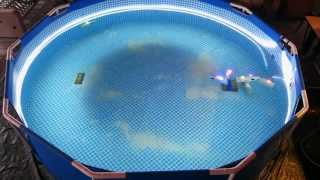
This video shows the CoCoRo autonomous underwater vehicles (AUVs) in a large aquarium at the CeBIT exhibition.
This experimental setup simulates a real mission scenario in which the AUVs have to collectively find an object of potential interest at the sea floor (e.g., a black box of a crashed plane).
In the beginning the AUVs start randomly distributed in the mission area (= aquarium) where the object is assumed to be.
The AUVs do not perform a special search pattern but instead use a simple random walk. Due to the high number of AUVs, quite soon one of the AUVs will be near the object (in this case a magnetic target) and can perceive it.
The AUV then tries to keep its position above the object and starts to emit blue-light signals that attract other nearby AUVs which in turn also emit blue-light signals. This leads to a fast aggregation of most of the swarm AUVs near the object.
In future underwater swarms these AUVs could then collectively grab and lift the object to the water surface.
More Youtube videos and other material can be seen on our homepage here:
http://cocoro.uni-graz.at/
Project funded by European Commission FP7.
This video shows the CoCoRo autonomous underwater vehicles (AUVs) in a large aquarium at the CeBIT exhibition.
This experimental setup simulates a real mission scenario in which the AUVs have to collectively find an object of potential interest at the sea floor (e.g., a black box of a crashed plane).
In the beginning the AUVs start randomly distributed in the mission area (= aquarium) where the object is assumed to be.
The AUVs do not perform a special search pattern but instead use a simple random walk. Due to the high number of AUVs, quite soon one of the AUVs will be near the object (in this case a magnetic target) and can perceive it.
The AUV then tries to keep its position above the object and starts to emit blue-light signals that attract other nearby AUVs which in turn also emit blue-light signals. This leads to a fast aggregation of most of the swarm AUVs near the object.
In future underwater swarms these AUVs could then collectively grab and lift the object to the water surface.
More Youtube videos and other material can be seen on our homepage here:
http://cocoro.uni-graz.at/
Project funded by European Commission FP7.