Uploaded February 2019 | Updated September 2026, 3 weeks ago
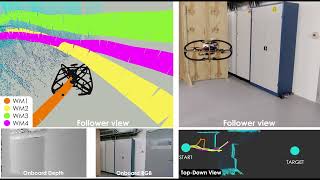
In this video we present a comprehensive result of field evaluation of the CERBERUS Aerial Scouts. The robots rely on a multi-modal localization and mapping solution enabling autonomy in subterranean settings. A graph-based path planning is further developed to ensure efficient and long-term autonomy in the multi-branching and geometrically complex underground domains. The presented result took place during the CERBERUS team 1st integration week at the Gonzen Mine in Switzerland.
In this video we present a comprehensive result of field evaluation of the CERBERUS Aerial Scouts. The robots rely on a multi-modal localization and mapping solution enabling autonomy in subterranean settings. A graph-based path planning is further developed to ensure efficient and long-term autonomy in the multi-branching and geometrically complex underground domains. The presented result took place during the CERBERUS team 1st integration week at the Gonzen Mine in Switzerland.