Uploaded May 2018 | Updated September 2026, 2 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Thu PM Pod R.1
Authors: Laursen, Johan Sund; Sørensen, Lars Carøe; Schultz, Ulrik Pagh; Ellekilde, Lars-Peter; Kraft, Dirk
Title: Adapting Parameterized Motions Using Iterative Learning and Online Collision Detection
Abstract:
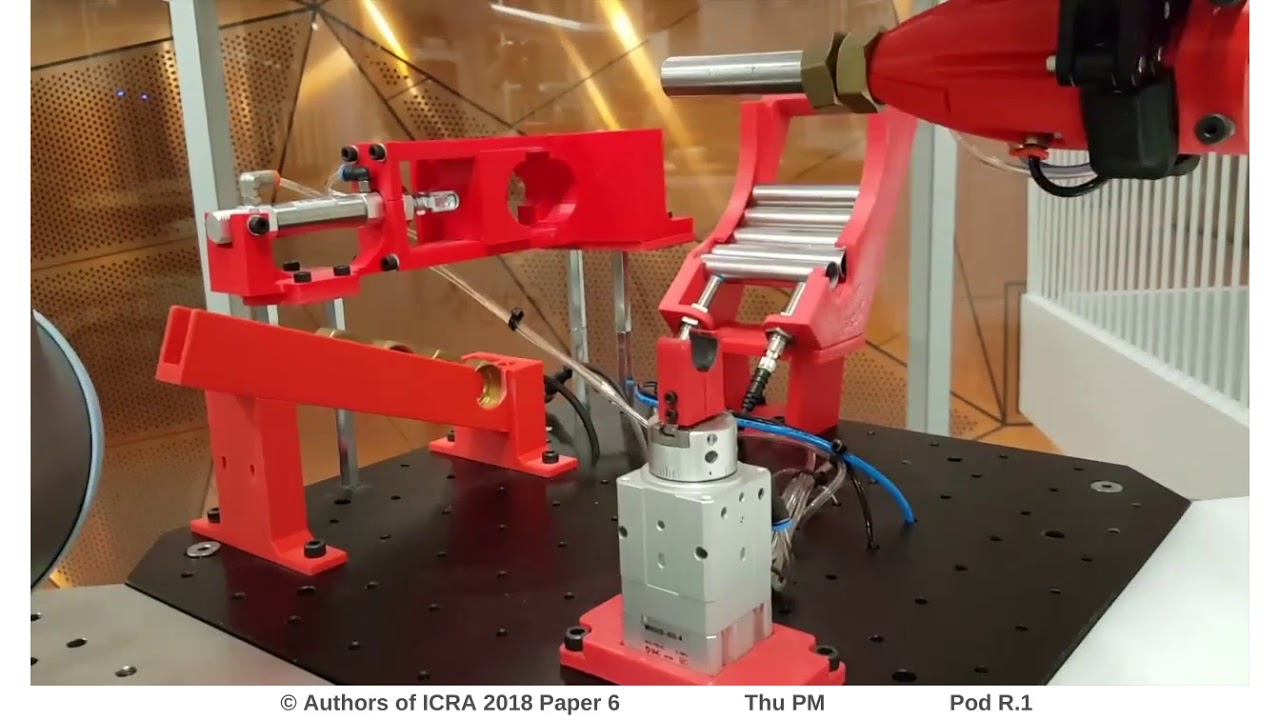
Achieving both the flexibility and robustness required to advance the use of robotics in small and medium-sized productions is an essential but difficult task. A fundamental problem is making the robot run blindly without additional sensors while still being robust to uncertainties and variations in the assembly processes. In this paper, we address the use of parameterized motions suitable for blind execution and robust to uncertainties in the assembly process. Collisions and incorrect assemblies are detected based on robot motor currents while motion parameters are updated based on Bayesian Optimization utilizing Gaussian Process learning. This allows for motion parameters to be optimized using real world trials which incorporate all uncertainties inherent in the assembly process without requiring advanced robot and sensor setups. The result is a simple and straightforward system which helps the user automatically find robust and uncertainty-tolerant motions. We present experiments for an assembly case showing both detection and learning in the real world and how these combine to a robust robot system.
ICRA 2018 Spotlight Video
Interactive Session Thu PM Pod R.1
Authors: Laursen, Johan Sund; Sørensen, Lars Carøe; Schultz, Ulrik Pagh; Ellekilde, Lars-Peter; Kraft, Dirk
Title: Adapting Parameterized Motions Using Iterative Learning and Online Collision Detection
Abstract:
Achieving both the flexibility and robustness required to advance the use of robotics in small and medium-sized productions is an essential but difficult task. A fundamental problem is making the robot run blindly without additional sensors while still being robust to uncertainties and variations in the assembly processes. In this paper, we address the use of parameterized motions suitable for blind execution and robust to uncertainties in the assembly process. Collisions and incorrect assemblies are detected based on robot motor currents while motion parameters are updated based on Bayesian Optimization utilizing Gaussian Process learning. This allows for motion parameters to be optimized using real world trials which incorporate all uncertainties inherent in the assembly process without requiring advanced robot and sensor setups. The result is a simple and straightforward system which helps the user automatically find robust and uncertainty-tolerant motions. We present experiments for an assembly case showing both detection and learning in the real world and how these combine to a robust robot system.