Uploaded May 2018 | Updated November 2026, 3 hours ago
ICRA 2018 Spotlight Video
Interactive Session Tue AM Pod N.7
Authors: Takata, Atsushi; Endo, Gen; Suzumori, Koichi; Nabae, Hiroyuki; Mizutani, Yoshihiro; Suzuki, Yoshiro
Title: Modeling of Synthetic Fiber Ropes and Frequency Response of Long-distance Cable-Pulley System
Abstract:
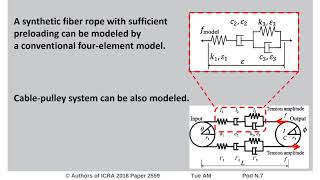
In recent years, synthetic fiber ropes have attracted much attention because of their potential to increase the load capacity, reduce the size, and lighten the weight of tendon-driven mechanisms. However, the mechanical characteristics of synthetic fiber ropes in a dynamic loading situation remain an open problem because of their visco-elasto-plasticity. This paper focuses on modeling synthetic fiber ropes, and the frequency response of a long-distance cable-pulley system for a tendon-driven robot. We show that a synthetic fiber rope can be modeled by Flory's model, and that it can be reduced to a conventional four-element model with sufficient preloading. After empirically acquiring the parameters of the four-element model for four different synthetic fiber ropes, each frequency response of a long-distance cable-pulley servo system was measured and compared to the analytical results based on the model, as well as the results of a stainless wire rope. Consequently, we show that synthetic fiber ropes achieved comparable bandwidth to that of the stainless wire rope. The damping of synthetic fiber ropes was found to suppress the servo system gain. This is useful for joint control of a tendon-driven robot with a relatively large amount of inertia, such as a long-reach robot arm.
ICRA 2018 Spotlight Video
Interactive Session Tue AM Pod N.7
Authors: Takata, Atsushi; Endo, Gen; Suzumori, Koichi; Nabae, Hiroyuki; Mizutani, Yoshihiro; Suzuki, Yoshiro
Title: Modeling of Synthetic Fiber Ropes and Frequency Response of Long-distance Cable-Pulley System
Abstract:
In recent years, synthetic fiber ropes have attracted much attention because of their potential to increase the load capacity, reduce the size, and lighten the weight of tendon-driven mechanisms. However, the mechanical characteristics of synthetic fiber ropes in a dynamic loading situation remain an open problem because of their visco-elasto-plasticity. This paper focuses on modeling synthetic fiber ropes, and the frequency response of a long-distance cable-pulley system for a tendon-driven robot. We show that a synthetic fiber rope can be modeled by Flory's model, and that it can be reduced to a conventional four-element model with sufficient preloading. After empirically acquiring the parameters of the four-element model for four different synthetic fiber ropes, each frequency response of a long-distance cable-pulley servo system was measured and compared to the analytical results based on the model, as well as the results of a stainless wire rope. Consequently, we show that synthetic fiber ropes achieved comparable bandwidth to that of the stainless wire rope. The damping of synthetic fiber ropes was found to suppress the servo system gain. This is useful for joint control of a tendon-driven robot with a relatively large amount of inertia, such as a long-reach robot arm.