Uploaded May 2018 | Updated November 2026, 3 hours ago
ICRA 2018 Spotlight Video
Interactive Session Wed AM Pod S.7
Authors: Sun, Guangli; LI, Xiang; Li, Peng; Liu, Yunhui
Title: A Synchronization Scheme for Position Control of Multiple Rope-Climbing Robots
Abstract:
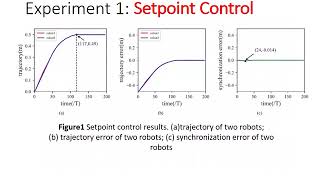
The ability of rope-climbing robots in aloft operation is limited by its self-supporting and locomotion ability. In many applications, a given task is also too complex to be achieved by a single rope-climbing robot acting alone. The solution of multiple rope-climbing robots can overcome the limitations. However, existing control methods for rope climbing robots are limited to single robot, and the open issue of coordination between multiple rope-climbing robots has not been systematically addressed. This paper presents a new synchronization scheme for position control of multiple ropeclimbing robots, such that each robot moves to the corresponding desired position while synchronizing the heights between each other. Maintaining the same height is very important to guarantee the stability of the task-oriented manipulator installed among multiple robots, when it is performing the manipulation task.The development of the proposed controller is based on the singular perturbation approach, by treating the fast actuator dynamics as a perturbation of the slow robot dynamics, such that the lowest control complexity is achieved. The exponential stability of the overall system that consists of the fast and slow subsystems is proved by using Tikhonov s theorem. Experimental results are presented to illustrate the performance of the proposed controller.
ICRA 2018 Spotlight Video
Interactive Session Wed AM Pod S.7
Authors: Sun, Guangli; LI, Xiang; Li, Peng; Liu, Yunhui
Title: A Synchronization Scheme for Position Control of Multiple Rope-Climbing Robots
Abstract:
The ability of rope-climbing robots in aloft operation is limited by its self-supporting and locomotion ability. In many applications, a given task is also too complex to be achieved by a single rope-climbing robot acting alone. The solution of multiple rope-climbing robots can overcome the limitations. However, existing control methods for rope climbing robots are limited to single robot, and the open issue of coordination between multiple rope-climbing robots has not been systematically addressed. This paper presents a new synchronization scheme for position control of multiple ropeclimbing robots, such that each robot moves to the corresponding desired position while synchronizing the heights between each other. Maintaining the same height is very important to guarantee the stability of the task-oriented manipulator installed among multiple robots, when it is performing the manipulation task.The development of the proposed controller is based on the singular perturbation approach, by treating the fast actuator dynamics as a perturbation of the slow robot dynamics, such that the lowest control complexity is achieved. The exponential stability of the overall system that consists of the fast and slow subsystems is proved by using Tikhonov s theorem. Experimental results are presented to illustrate the performance of the proposed controller.