Uploaded May 2018 | Updated November 2026, 3 minutes ago
ICRA 2018 Spotlight Video
Interactive Session Wed AM Pod U.5
Authors: Giamou, Matthew; Khosoussi, Kasra; How, Jonathan Patrick
Title: Talk Resource-Efficiently to Me: Optimal Communication Planning for Distributed Loop Closure Detection
Abstract:
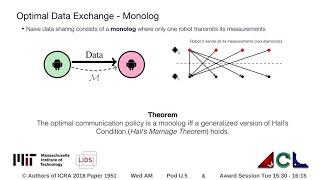
Due to the distributed nature of cooperative simultaneous localization and mapping (CSLAM), detecting inter-robot loop closures necessitates sharing sensory data with other robots. A naive approach to data sharing can easily lead to a waste of mission-critical resources. This paper investigates the logistical aspects of CSLAM. Particularly, we present a general resource-efficient communication planning framework that takes into account both the total amount of exchanged data and the induced division of labor between the participating robots. Compared to other state-of-the-art approaches, our framework is able to verify the same set of potential inter-robot loop closures while exchanging considerably less data and influencing the induced workloads. We develop a fast algorithm for finding globally optimal communication policies, and present theoretical analysis to characterize the necessary and sufficient conditions under which simpler strategies are optimal. The proposed framework is extensively evaluated with data from the KITTI odometry benchmark datasets.
ICRA 2018 Spotlight Video
Interactive Session Wed AM Pod U.5
Authors: Giamou, Matthew; Khosoussi, Kasra; How, Jonathan Patrick
Title: Talk Resource-Efficiently to Me: Optimal Communication Planning for Distributed Loop Closure Detection
Abstract:
Due to the distributed nature of cooperative simultaneous localization and mapping (CSLAM), detecting inter-robot loop closures necessitates sharing sensory data with other robots. A naive approach to data sharing can easily lead to a waste of mission-critical resources. This paper investigates the logistical aspects of CSLAM. Particularly, we present a general resource-efficient communication planning framework that takes into account both the total amount of exchanged data and the induced division of labor between the participating robots. Compared to other state-of-the-art approaches, our framework is able to verify the same set of potential inter-robot loop closures while exchanging considerably less data and influencing the induced workloads. We develop a fast algorithm for finding globally optimal communication policies, and present theoretical analysis to characterize the necessary and sufficient conditions under which simpler strategies are optimal. The proposed framework is extensively evaluated with data from the KITTI odometry benchmark datasets.