Uploaded May 2018 | Updated November 2026, 13 minutes ago
ICRA 2018 Spotlight Video
Interactive Session Wed PM Pod O.6
Authors: Hu, Yang; GU, YUN; yang, jie; Yang, Guang-Zhong
Title: Multi-Stage Suture Detection for Robot Assisted Anastomosis Based on Deep Learning
Abstract:
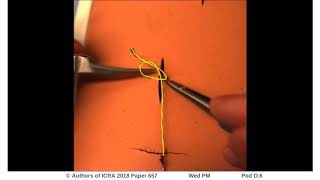
In robotic surgery, task automation and learning from demonstration combined with human supervision is an emerging trend for many new surgical robot platforms. One such task is automated anastomosis, which requires bimanual needle handling and suture detection. Due to the complexity of the surgical environment and varying patient anatomies, reliable suture detection is difficult, which is further complicated by occlusion and thread topologies. In this paper, we propose a multi-stage framework for suture thread detection based on deep learning. Fully convolutional neural networks are used to obtain the initial detection and the overlapping status of suture thread, which are later fused with the original image to learn a gradient road map of the thread. Based on the gradient road map, multiple segments of the thread are extracted and linked to form the whole thread using a curvilinear structure detector. Experiments on two different types of sutures demonstrate the accuracy of the proposed framework.
ICRA 2018 Spotlight Video
Interactive Session Wed PM Pod O.6
Authors: Hu, Yang; GU, YUN; yang, jie; Yang, Guang-Zhong
Title: Multi-Stage Suture Detection for Robot Assisted Anastomosis Based on Deep Learning
Abstract:
In robotic surgery, task automation and learning from demonstration combined with human supervision is an emerging trend for many new surgical robot platforms. One such task is automated anastomosis, which requires bimanual needle handling and suture detection. Due to the complexity of the surgical environment and varying patient anatomies, reliable suture detection is difficult, which is further complicated by occlusion and thread topologies. In this paper, we propose a multi-stage framework for suture thread detection based on deep learning. Fully convolutional neural networks are used to obtain the initial detection and the overlapping status of suture thread, which are later fused with the original image to learn a gradient road map of the thread. Based on the gradient road map, multiple segments of the thread are extracted and linked to form the whole thread using a curvilinear structure detector. Experiments on two different types of sutures demonstrate the accuracy of the proposed framework.