Uploaded May 2018 | Updated September 2026, 2 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Wed PM Pod C.7
Authors: Kamikawa, Yasuhisa; Enayati, Nima; Okamura, Allison M.
Title: Magnified Force Sensory Substitution for Telemanipulation Via Force-Controlled Skin Deformation
Abstract:
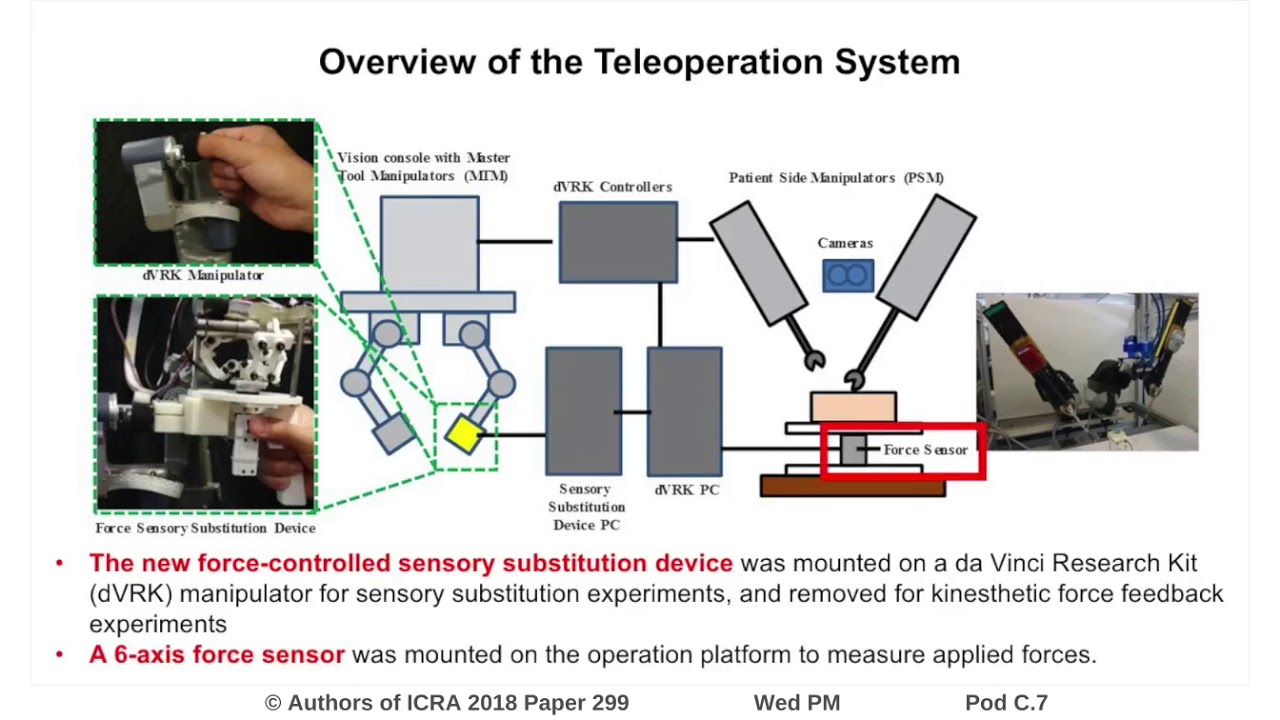
Teleoperation systems could benefit from force sensory substitution when kinesthetic force feedback systems are too bulky or expensive, and when they cause instability by magnifying force feedback. We aim to magnify force feedback using sensory substitution via force-controlled tactile skin deformation, using a device with the ability to provide tangential and normal force directly to the fingerpads. The sensory substitution device is able to provide skin deformation force feedback over ten times the maximum stable kinesthetic force feedback on a da Vinci Research Kit teleoperation system. We evaluated the effect of this force magnification in two experimental tasks where the goal was to minimize interaction force with the environment. In a peg transfer task, magnified force feedback using sensory substitution improved participants performance for force magnifications up to ten times, but decreased performance for higher force magnifications. In a tube connection task, sensory substitution that doubled the force feedback maximized performance; there was no improvement at the larger magnifications. These experiments demonstrate that magnified force feedback using sensory substitution via force-controlled skin deformation feedback can decrease applied forces similarly to magnified kinesthetic force feedback during teleoperation.
ICRA 2018 Spotlight Video
Interactive Session Wed PM Pod C.7
Authors: Kamikawa, Yasuhisa; Enayati, Nima; Okamura, Allison M.
Title: Magnified Force Sensory Substitution for Telemanipulation Via Force-Controlled Skin Deformation
Abstract:
Teleoperation systems could benefit from force sensory substitution when kinesthetic force feedback systems are too bulky or expensive, and when they cause instability by magnifying force feedback. We aim to magnify force feedback using sensory substitution via force-controlled tactile skin deformation, using a device with the ability to provide tangential and normal force directly to the fingerpads. The sensory substitution device is able to provide skin deformation force feedback over ten times the maximum stable kinesthetic force feedback on a da Vinci Research Kit teleoperation system. We evaluated the effect of this force magnification in two experimental tasks where the goal was to minimize interaction force with the environment. In a peg transfer task, magnified force feedback using sensory substitution improved participants performance for force magnifications up to ten times, but decreased performance for higher force magnifications. In a tube connection task, sensory substitution that doubled the force feedback maximized performance; there was no improvement at the larger magnifications. These experiments demonstrate that magnified force feedback using sensory substitution via force-controlled skin deformation feedback can decrease applied forces similarly to magnified kinesthetic force feedback during teleoperation.