Uploaded July 2024 | Updated September 2026, 1 week ago
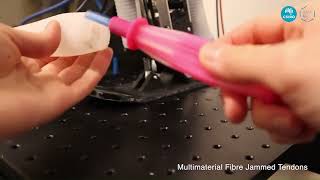
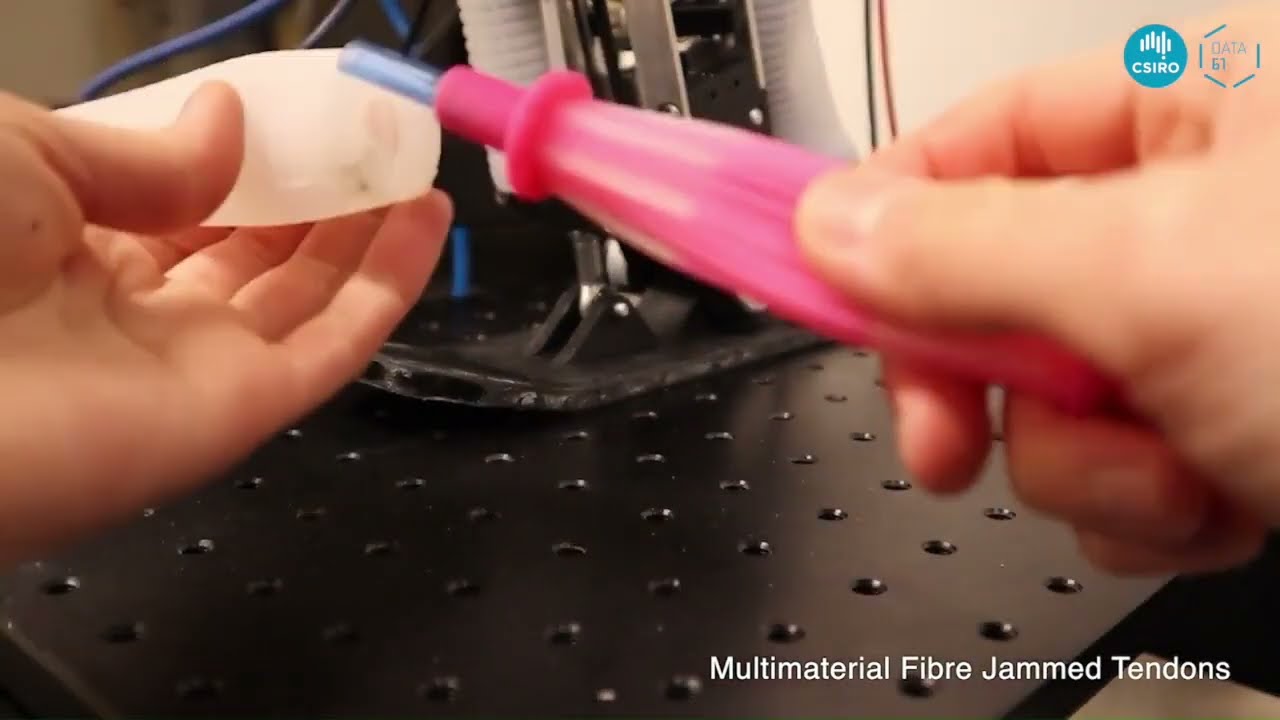
Humans possess a remarkable ability to react to unpredictable perturbations through immediate mechanical responses, which harness the visco-elastic properties of muscles to maintain balance. Inspired by this behaviour, we propose a novel design of a robotic leg utilising fibre jammed structures as passive compliant mechanisms to achieve variable joint stiffness and damping. We developed multi-material fibre jammed tendons with tunable mechanical properties, which can be 3D printed in one-go without need for assembly. Through extensive numerical simulations and experimentation, we demonstrate the usefulness of these tendons for shock absorbance and maintaining joint stability. We investigate how they could be used effectively in a multi-joint robotic leg by evaluating the relative contribution of each tendon to the overall stiffness of the leg. Further, we showcase the potential of these jammed structures for legged locomotion, highlighting how morphological properties of the tendons can be used to enhance stability in robotic legs.
Full paper: arxiv.org/pdf/2308.01758
Humans possess a remarkable ability to react to unpredictable perturbations through immediate mechanical responses, which harness the visco-elastic properties of muscles to maintain balance. Inspired by this behaviour, we propose a novel design of a robotic leg utilising fibre jammed structures as passive compliant mechanisms to achieve variable joint stiffness and damping. We developed multi-material fibre jammed tendons with tunable mechanical properties, which can be 3D printed in one-go without need for assembly. Through extensive numerical simulations and experimentation, we demonstrate the usefulness of these tendons for shock absorbance and maintaining joint stability. We investigate how they could be used effectively in a multi-joint robotic leg by evaluating the relative contribution of each tendon to the overall stiffness of the leg. Further, we showcase the potential of these jammed structures for legged locomotion, highlighting how morphological properties of the tendons can be used to enhance stability in robotic legs.
Full paper: arxiv.org/pdf/2308.01758