Uploaded September 2015 | Updated September 2026, 1 week ago
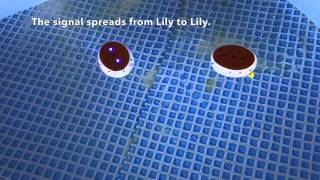
The Year of CoCoRo 36B/52: This video shows the real-world experiments performed in the "relay swarm" scenario. First Jeff robots search the ground of a fragmented habitat for a magnetic target. As soon as it finds the target it signals this locally with blue-light LEDs. Lily robots that also roam the habitat can pick up the signal from this Jeff robot. The info can also spread from Lily robot to Lily robot as they meet, it spreads like in an infectious process. Finally, Lily robots inform the surface station that the Jeff robot on the ground has found an interesting target. Future extensions foresee that after informing the surface station another phase starts: A second signal spreads from the surface station through the Lily robots back to the Jeff robot on the ground, ultimately make the Jeff robot to go up to the surface above the found target.
The Year of CoCoRo 36B/52: This video shows the real-world experiments performed in the "relay swarm" scenario. First Jeff robots search the ground of a fragmented habitat for a magnetic target. As soon as it finds the target it signals this locally with blue-light LEDs. Lily robots that also roam the habitat can pick up the signal from this Jeff robot. The info can also spread from Lily robot to Lily robot as they meet, it spreads like in an infectious process. Finally, Lily robots inform the surface station that the Jeff robot on the ground has found an interesting target. Future extensions foresee that after informing the surface station another phase starts: A second signal spreads from the surface station through the Lily robots back to the Jeff robot on the ground, ultimately make the Jeff robot to go up to the surface above the found target.