Uploaded April 2026 | Updated September 2026, 3 hours ago
This video demonstrates aTriple Inverted Pendulum Stabilization using LQR & UKF in MATLAB.
The system is controlled using a Linear Quadratic Regulator (LQR) and its states are estimated using an Unscented Kalman Filter (UKF), making it a powerful example of nonlinear control in robotics and engineering.
🔧 Key Features:
Nonlinear dynamic modeling
Optimal control using LQR
State estimation using UKF
Real-time simulation and animation
MATLAB-based implementation
This project is ideal for:
Control Systems Engineering
Robotics and Automation
MATLAB/Simulink learners
Research and academic projects
📦 Full MATLAB project files available
🎓 Suitable for final year projects and research work
triple inverted pendulum
inverted pendulum matlab
lqr controller matlab
unscented kalman filter ukf
kalman filter matlab simulation
control systems engineering
robotics matlab simulation
nonlinear control system
matlab engineering project
final year engineering project
robotics control system
state estimation ukf
lqr vs pid control
advanced control systems
automation engineering,Triple Inverted Pendulum, LQR, UKF, Stabilization, Control Systems, Robotics, Engineering, Linear Quadratic Regulator, Unscented Kalman Filter, System Identification, State Estimation, Dynamic Systems, Advanced Control, Pendulum Control, Mechatronics, PID Control, Modern Control, Control Theory, Simulation, Experiment
#shorts
#matlab
#engineering
#controlsystems
#robotics
#lqr
#kalmanfilter
#ukf
#simulation
#automation
#nonlinear
#stem
#engineeringprojects
#finalyearproject
#fyp
This video demonstrates aTriple Inverted Pendulum Stabilization using LQR & UKF in MATLAB.
The system is controlled using a Linear Quadratic Regulator (LQR) and its states are estimated using an Unscented Kalman Filter (UKF), making it a powerful example of nonlinear control in robotics and engineering.
🔧 Key Features:
Nonlinear dynamic modeling
Optimal control using LQR
State estimation using UKF
Real-time simulation and animation
MATLAB-based implementation
This project is ideal for:
Control Systems Engineering
Robotics and Automation
MATLAB/Simulink learners
Research and academic projects
📦 Full MATLAB project files available
🎓 Suitable for final year projects and research work
triple inverted pendulum
inverted pendulum matlab
lqr controller matlab
unscented kalman filter ukf
kalman filter matlab simulation
control systems engineering
robotics matlab simulation
nonlinear control system
matlab engineering project
final year engineering project
robotics control system
state estimation ukf
lqr vs pid control
advanced control systems
automation engineering,Triple Inverted Pendulum, LQR, UKF, Stabilization, Control Systems, Robotics, Engineering, Linear Quadratic Regulator, Unscented Kalman Filter, System Identification, State Estimation, Dynamic Systems, Advanced Control, Pendulum Control, Mechatronics, PID Control, Modern Control, Control Theory, Simulation, Experiment
#shorts
#matlab
#engineering
#controlsystems
#robotics
#lqr
#kalmanfilter
#ukf
#simulation
#automation
#nonlinear
#stem
#engineeringprojects
#finalyearproject
#fyp



![Assignment MN5621- Synthesis and Dynamic Simulation of a Mechanism Brunel university assignment CAE
📌Email:mrengineer294@gmail.com
📌Buy me a Coffee: https://buymeacoffee.com/engrprogrammer
📌Follow me on instagram : https://www.instagram.com/engrprogrammer2494/
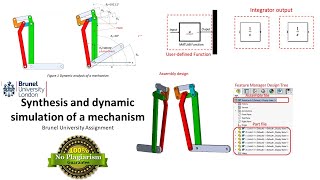
⛔Welcome to todays tech.. this video is about the solution of Assignment MN5621- Synthesis and Dynamic Simulation of a Mechanism | Brunel university assignment
.............................................................................................................................
if you need the solution of this assignment then feel free to contact me, i assure you that i will provide you plagiarism free solution and you will get good grades
Contact me on following details
Email: mrengineer294@gmail.com
Website: https://engrprogrammer.com/engineering-blogs/
.............................................................................................................................
📌Question 1:
Given a mechanism with the link lengths as shown in the separate attachment, that can be found under appendix A
Answer the following the questions for the open and crossed circuits of the linkage assuming, θ5= 100.02⸰, ω5 = 5 rad/sec, and α5 = 1 rad/sec2. The mass density is
ρ=30000kg/m3, and the link thickness T is 0.02 m.
1) Find the values of θ2, θ3, θ4, and θ6.
2) Find the values of ω2, ω3, ω4, and ω6.
3) Find the values of α2, α3, α4, and α6.
4) Find the centre of mass values for the orange and red links, respectively.
5) Determine the acceleration values at the centre of mass for the red and orange links, measured from the origin (see Figure 1).
📌Question 2:
For the mechanism described in Question 1, simulate it for the case in which the motion begins with a given crank angle θ5[rad] (find it in the figure), a given crank angular velocity ω5 = 0.2 rad/s and a given angular acceleration α5 = 0.05 rad/s2 in the link.
The derived equations in Question 1 will be used to solve Question 2 using a MATLAB User-defined function that will take all of the integrator outputs as input arguments (Figure 2).
1) Plot the values of θ2, θ3, θ4, and θ6 for the first 1 second.
2) Plot the values of ω2, ω3, ω4, and ω6 for the first 1 second.
3) Plot the values of α2, α3, α4, and α6 for the first 1 second.
4) Plot the values of acceleration of orange and red links, measured from the
origin from the first 1 second.
Note: Regarding question 1, you have to write down the complete derivation of 1) to 5) rather than the final equation, and you have to write the assignment using MS WORD (please see an attached example assignment). I do not accept a handwriting report, and it will be 0 points
📌Question 3:
Create links 1, 2, 3, 4, 5, 6, and 7 respectively, and assemble them using Solidworks
(any version is okay).
1) You need to check whether the assembled mechanism works or not. If the design of the parts and the assembly are correct, the mechanism will work when the red link is rotated by you (note that the orange link is connected to the green link with a “Concentric Mate”, and the green links should be fixed).
2) Denote the dimensions of the mechanism when the angle of the red link is roughly adjusted to 100 [deg] as shown in Figure 2, and save them.
3) In the assignment, you need to put the screen capture images of your assembly design and Feature Manager Design Tree as shown below.
.............................................................................................................................
Todays tech,synthesis and dynamic simulation of a six-bar linkage,synthesis of mechanism,simulation,mechanism design,mechanism,synthesis,static analysis of four bar mechanism,static force analysis of mechanism,dynamic simulation,analysis and synthesis,velocity analysis of 4 bar mechanism,dynamics of six bar linkage,mechanism analysis,brunel,Mechanism,Synthesis and Dynamic Simulation of a Mechanism,Computer aided engineering,MN5621,Yohan Noh
#yohannoh #bruneluniversity #CAE #mechanism #assignment Assignment MN5621- Synthesis and Dynamic Simulation of a Mechanism Brunel university assignment CAE](https://i.ytimg.com/vi/2_MB6cufteM/mqdefault.jpg)