Uploaded November 2025 | Updated September 2026, 4 hours ago
📌download code 👇
engrprogrammer-shop.fourthwall.com/products/matlab-path-planning-algorithms-pack-astar-dijkstra-rrt-rrtstar-prm-full-code-animations
Watch how a robot explores a 2D map using Rapidly-Exploring Random Trees (RRT) in MATLAB! This animation shows a clean, fast, and visually stunning path from start to goal, avoiding obstacles.
✅ Features:
Dynamic live animation of RRT
MP4 and GIF export ready
Extra 5 seconds to admire the final path
Goal-biased exploration for faster convergence
Perfect for learning, robotics, and simulation enthusiasts
💡 Learn how RRT differs from Dijkstra and A* – see how random exploration quickly finds paths even in complex maps.
Download the MATLAB code and start experimenting today!
rrt* path planning, path planning, robot path planning, drone path planning, path planning algorithm, path planning algorithms, robot path planning with avoiding obstacles, probabilistic path planning algorithms, path planning and obstacle avoidance, obstacle avoidance and path planning, path planning algorithms for mobile robots, quadcopter simulation in matlab, simulation of drone in matlab, how to make a drone simulation in matlab, simulation of quadcopter in matlab, how to make a drone simulator in matlab
#MATLAB #RRT #PathPlanning #Robotics #RobotSimulation #AlgorithmAnimation #AI #MachineLearning #AutonomousRobots #TechExplained #STEM #Programming #RobotPathfinding #LearnMATLAB #EngineeringSimulation
📌download code 👇
engrprogrammer-shop.fourthwall.com/products/matlab-path-planning-algorithms-pack-astar-dijkstra-rrt-rrtstar-prm-full-code-animations
Watch how a robot explores a 2D map using Rapidly-Exploring Random Trees (RRT) in MATLAB! This animation shows a clean, fast, and visually stunning path from start to goal, avoiding obstacles.
✅ Features:
Dynamic live animation of RRT
MP4 and GIF export ready
Extra 5 seconds to admire the final path
Goal-biased exploration for faster convergence
Perfect for learning, robotics, and simulation enthusiasts
💡 Learn how RRT differs from Dijkstra and A* – see how random exploration quickly finds paths even in complex maps.
Download the MATLAB code and start experimenting today!
rrt* path planning, path planning, robot path planning, drone path planning, path planning algorithm, path planning algorithms, robot path planning with avoiding obstacles, probabilistic path planning algorithms, path planning and obstacle avoidance, obstacle avoidance and path planning, path planning algorithms for mobile robots, quadcopter simulation in matlab, simulation of drone in matlab, how to make a drone simulation in matlab, simulation of quadcopter in matlab, how to make a drone simulator in matlab
#MATLAB #RRT #PathPlanning #Robotics #RobotSimulation #AlgorithmAnimation #AI #MachineLearning #AutonomousRobots #TechExplained #STEM #Programming #RobotPathfinding #LearnMATLAB #EngineeringSimulation


![Assignment MN5621- Synthesis and Dynamic Simulation of a Mechanism Brunel university assignment CAE
📌Email:mrengineer294@gmail.com
📌Buy me a Coffee: https://buymeacoffee.com/engrprogrammer
📌Follow me on instagram : https://www.instagram.com/engrprogrammer2494/
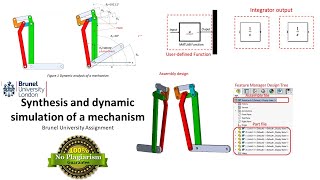
⛔Welcome to todays tech.. this video is about the solution of Assignment MN5621- Synthesis and Dynamic Simulation of a Mechanism | Brunel university assignment
.............................................................................................................................
if you need the solution of this assignment then feel free to contact me, i assure you that i will provide you plagiarism free solution and you will get good grades
Contact me on following details
Email: mrengineer294@gmail.com
Website: https://engrprogrammer.com/engineering-blogs/
.............................................................................................................................
📌Question 1:
Given a mechanism with the link lengths as shown in the separate attachment, that can be found under appendix A
Answer the following the questions for the open and crossed circuits of the linkage assuming, θ5= 100.02⸰, ω5 = 5 rad/sec, and α5 = 1 rad/sec2. The mass density is
ρ=30000kg/m3, and the link thickness T is 0.02 m.
1) Find the values of θ2, θ3, θ4, and θ6.
2) Find the values of ω2, ω3, ω4, and ω6.
3) Find the values of α2, α3, α4, and α6.
4) Find the centre of mass values for the orange and red links, respectively.
5) Determine the acceleration values at the centre of mass for the red and orange links, measured from the origin (see Figure 1).
📌Question 2:
For the mechanism described in Question 1, simulate it for the case in which the motion begins with a given crank angle θ5[rad] (find it in the figure), a given crank angular velocity ω5 = 0.2 rad/s and a given angular acceleration α5 = 0.05 rad/s2 in the link.
The derived equations in Question 1 will be used to solve Question 2 using a MATLAB User-defined function that will take all of the integrator outputs as input arguments (Figure 2).
1) Plot the values of θ2, θ3, θ4, and θ6 for the first 1 second.
2) Plot the values of ω2, ω3, ω4, and ω6 for the first 1 second.
3) Plot the values of α2, α3, α4, and α6 for the first 1 second.
4) Plot the values of acceleration of orange and red links, measured from the
origin from the first 1 second.
Note: Regarding question 1, you have to write down the complete derivation of 1) to 5) rather than the final equation, and you have to write the assignment using MS WORD (please see an attached example assignment). I do not accept a handwriting report, and it will be 0 points
📌Question 3:
Create links 1, 2, 3, 4, 5, 6, and 7 respectively, and assemble them using Solidworks
(any version is okay).
1) You need to check whether the assembled mechanism works or not. If the design of the parts and the assembly are correct, the mechanism will work when the red link is rotated by you (note that the orange link is connected to the green link with a “Concentric Mate”, and the green links should be fixed).
2) Denote the dimensions of the mechanism when the angle of the red link is roughly adjusted to 100 [deg] as shown in Figure 2, and save them.
3) In the assignment, you need to put the screen capture images of your assembly design and Feature Manager Design Tree as shown below.
.............................................................................................................................
Todays tech,synthesis and dynamic simulation of a six-bar linkage,synthesis of mechanism,simulation,mechanism design,mechanism,synthesis,static analysis of four bar mechanism,static force analysis of mechanism,dynamic simulation,analysis and synthesis,velocity analysis of 4 bar mechanism,dynamics of six bar linkage,mechanism analysis,brunel,Mechanism,Synthesis and Dynamic Simulation of a Mechanism,Computer aided engineering,MN5621,Yohan Noh
#yohannoh #bruneluniversity #CAE #mechanism #assignment Assignment MN5621- Synthesis and Dynamic Simulation of a Mechanism Brunel university assignment CAE](https://i.ytimg.com/vi/2_MB6cufteM/mqdefault.jpg)