Uploaded May 2026 | Updated September 2026, 1 week ago
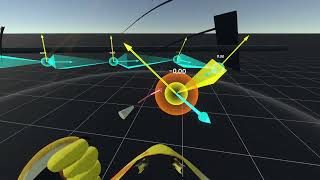
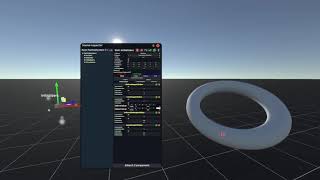
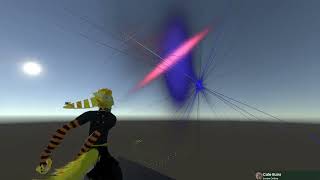
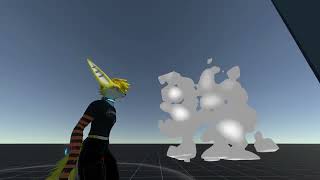
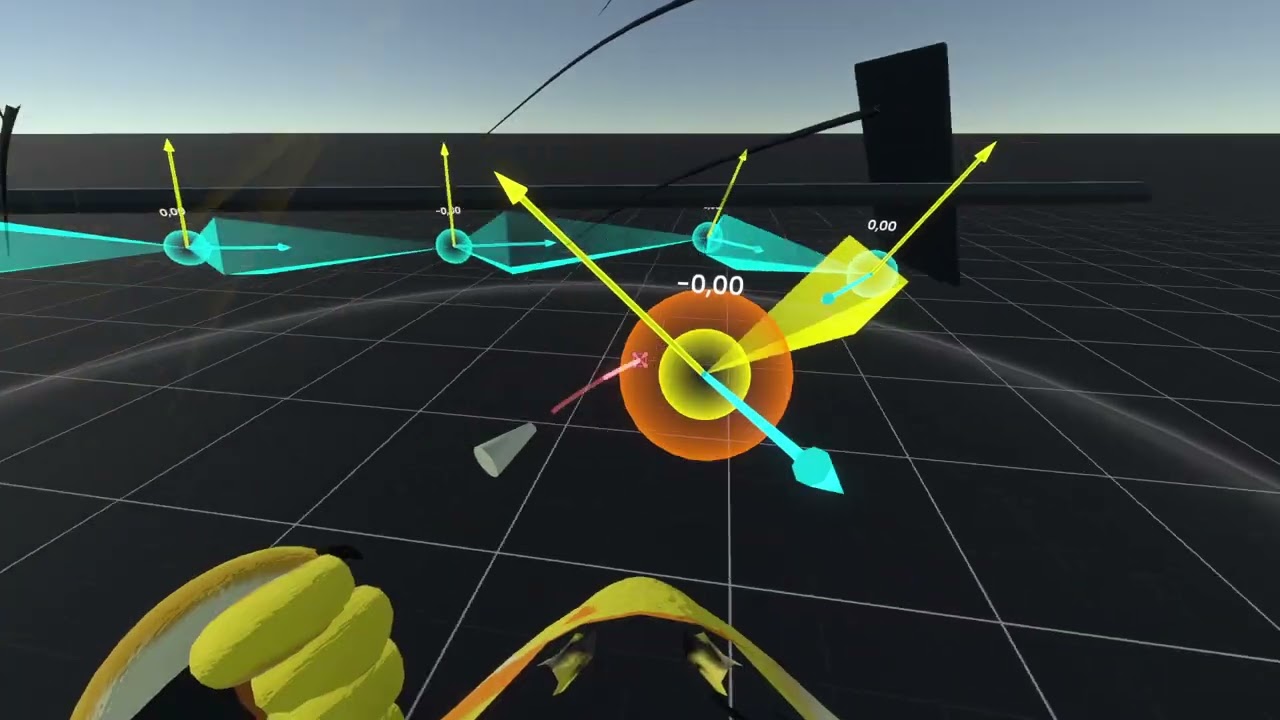
Another component of the IK solver is done! It can now properly resolve bone rotations & twists and propagate them through the chain!
This is technically not part of FABRIK itself - the algorithm specifically doesn't consider bone rotations for the core of it.
However computing orientations is important, because they need to be mapped to stuff that's being rendered and they'll also be necessary once constraints are implemented.
Now I can move on to the next parts! I'll probably be wrapping up a few things and I'll probably release the general FABRIK solver for everyone to play with soon!
My goal is to do incremental releases as each phase is done. This will NOT include any biped/full body stuff, that requires a bunch of other work, but I need to make sure this algorithm works properly first, because it's an important building block for it.
Support development at: patreon.com/resonite
Official website: resonite.com
Another component of the IK solver is done! It can now properly resolve bone rotations & twists and propagate them through the chain!
This is technically not part of FABRIK itself - the algorithm specifically doesn't consider bone rotations for the core of it.
However computing orientations is important, because they need to be mapped to stuff that's being rendered and they'll also be necessary once constraints are implemented.
Now I can move on to the next parts! I'll probably be wrapping up a few things and I'll probably release the general FABRIK solver for everyone to play with soon!
My goal is to do incremental releases as each phase is done. This will NOT include any biped/full body stuff, that requires a bunch of other work, but I need to make sure this algorithm works properly first, because it's an important building block for it.
Support development at: patreon.com/resonite
Official website: resonite.com