Uploaded August 2026 | Updated September 2026, 2 weeks ago
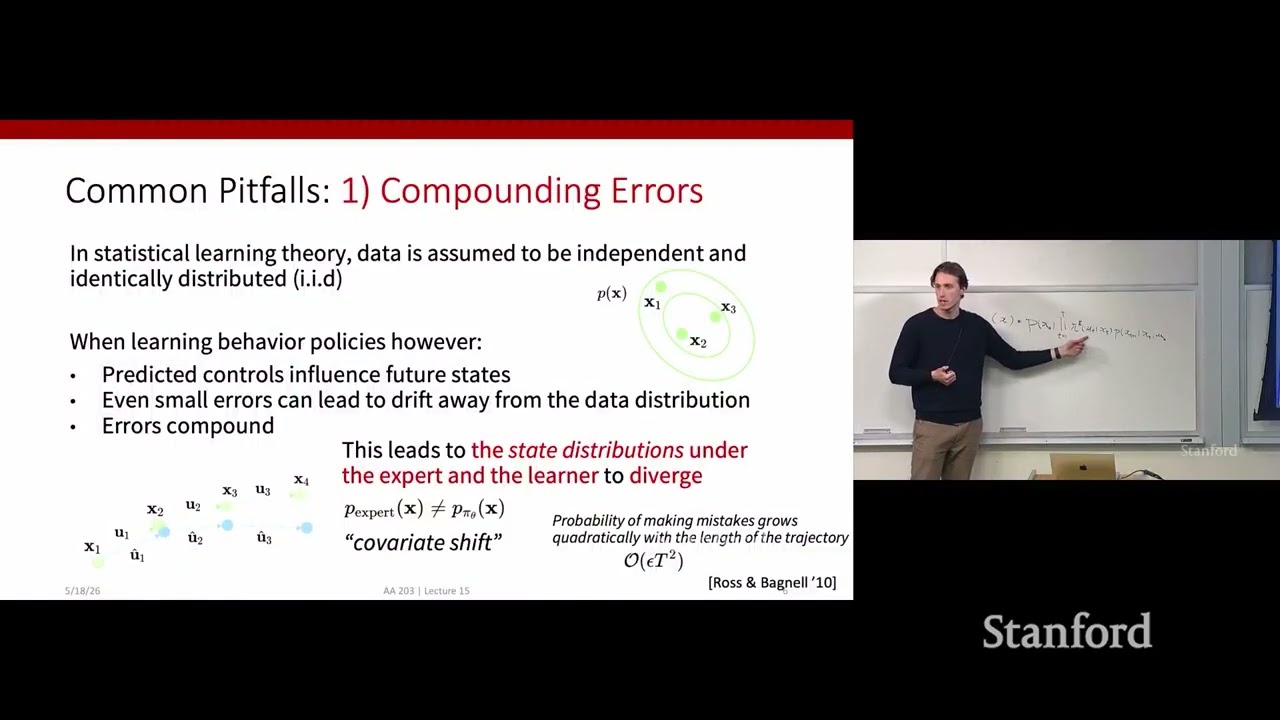
Lecture 15 — Imitation Learning
Read the companion textbook, Principles of Robot Autonomy, free online: porabook.com
To learn more about enrolling in AA203 Optimal and Learning-Based Control, visit: https://online.stanford.edu/courses/aa203-optimal-and-learning-based-control
Follow along with the course schedule and syllabus: stanfordasl.github.io/aa203/sp2526
Lecture slides: stanfordasl.github.io/aa203/sp2526/pdfs/lecture/lecture_4.pdf
Speaker: Dr. Daniele Gammelli
Bio: Dr. Daniele Gammelli is the Research Director of the Machine Intelligence for Robot Autonomy Laboratory at the Italian Institute of Artificial Intelligence (AI4I), and a Researcher in the Department of Aeronautics and Astronautics at Stanford University. Since 2022, he has been a Research Fellow at the Center for Aerospace Autonomy Research (CAESAR) at Stanford and, until 2025, at the Center for Automotive Research at Stanford (CARS). He received his Ph.D. in Machine Learning and Mathematical Optimization from the Technical University of Denmark (DTU) in 2022, where his doctoral thesis was nominated for the DTU Best Thesis of the Year Award and the DTU Young Researcher Award. Dr. Gammelli’s research focuses on developing the algorithmic foundations and system-level methodologies that enable AI-powered autonomous systems to operate safely, efficiently, and reliably in high-stakes environments, with an emphasis on aerospace autonomy and next-generation mobility systems.
Instructors:
Prof. Marco Pavone, Associate Professor of Aeronautics and Astronautics, Director of Autonomous Vehicle Research at NVIDIA
Dr. Daniele Gammelli, Research Director at the Italian Institute of Artificial Intelligence (AI4I), Researcher at the Department of Aeronautics and Astronautics, Stanford University
Full playlist: youtube.com/playlist?list=PLa9dmHsLK9dg
#StanfordOnline #OptimalControl #Robotics #PhysicalAI
Lecture 15 — Imitation Learning
Read the companion textbook, Principles of Robot Autonomy, free online: porabook.com
To learn more about enrolling in AA203 Optimal and Learning-Based Control, visit: https://online.stanford.edu/courses/aa203-optimal-and-learning-based-control
Follow along with the course schedule and syllabus: stanfordasl.github.io/aa203/sp2526
Lecture slides: stanfordasl.github.io/aa203/sp2526/pdfs/lecture/lecture_4.pdf
Speaker: Dr. Daniele Gammelli
Bio: Dr. Daniele Gammelli is the Research Director of the Machine Intelligence for Robot Autonomy Laboratory at the Italian Institute of Artificial Intelligence (AI4I), and a Researcher in the Department of Aeronautics and Astronautics at Stanford University. Since 2022, he has been a Research Fellow at the Center for Aerospace Autonomy Research (CAESAR) at Stanford and, until 2025, at the Center for Automotive Research at Stanford (CARS). He received his Ph.D. in Machine Learning and Mathematical Optimization from the Technical University of Denmark (DTU) in 2022, where his doctoral thesis was nominated for the DTU Best Thesis of the Year Award and the DTU Young Researcher Award. Dr. Gammelli’s research focuses on developing the algorithmic foundations and system-level methodologies that enable AI-powered autonomous systems to operate safely, efficiently, and reliably in high-stakes environments, with an emphasis on aerospace autonomy and next-generation mobility systems.
Instructors:
Prof. Marco Pavone, Associate Professor of Aeronautics and Astronautics, Director of Autonomous Vehicle Research at NVIDIA
Dr. Daniele Gammelli, Research Director at the Italian Institute of Artificial Intelligence (AI4I), Researcher at the Department of Aeronautics and Astronautics, Stanford University
Full playlist: youtube.com/playlist?list=PLa9dmHsLK9dg
#StanfordOnline #OptimalControl #Robotics #PhysicalAI