Uploaded October 2019 | Updated September 2026, 9 hours ago
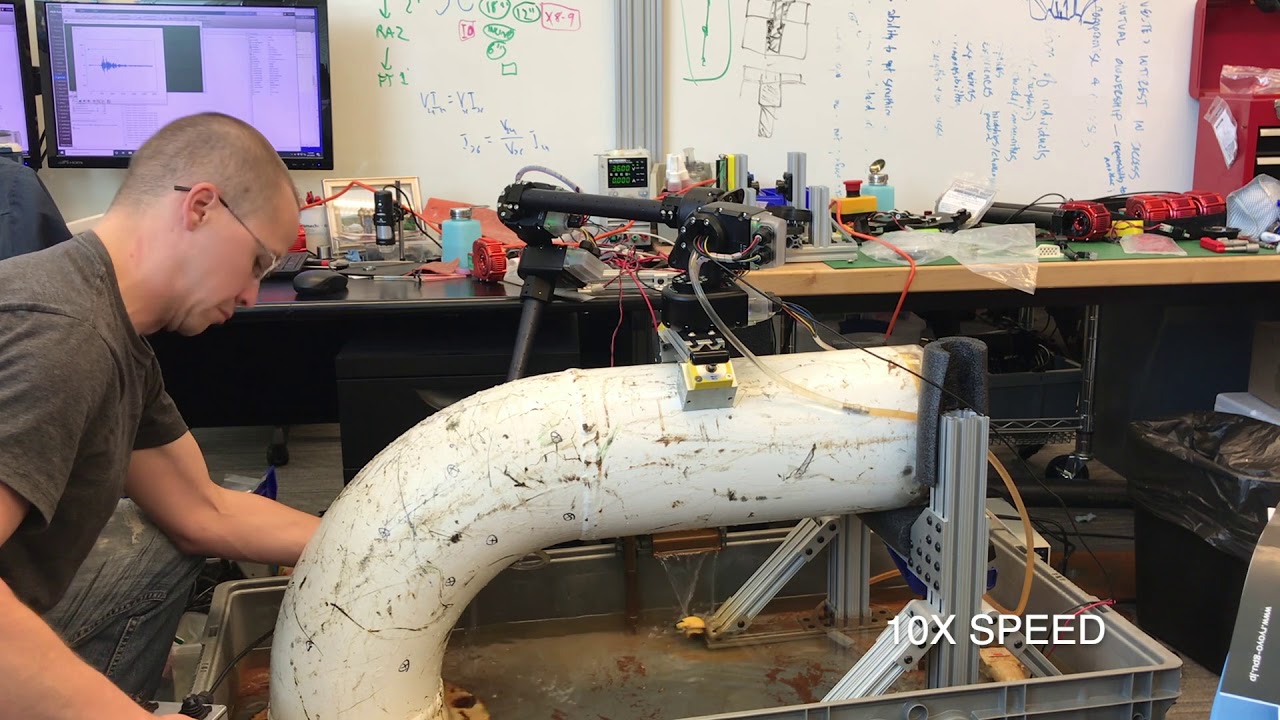
This video demonstrates the setup, training, and scanning of a pipe elbow using an ultrasonic (UT) thickness probe and an arm that was quickly built of HEBI's R-Series Actuators. The motion is trained by fitting a curved surface a handful of points, and then a dense raster scanning motion is planned and executed along the surface. During the scanning a 3D and unwrapped 2D depth map (C-Scan) is constructed in real time.
The water flowing out of the end of the arm is needed to sonically couple the probe to the surface, like the coupling gel used in a medical ultrasound. The arm itself is lightweight (less than 10 kg) and portable. Since the arm is modular it ca be reconfigured for larger, smaller, or hard-to-reach environments.
The method used to measure and train the surface is general and can be applied to a wide range of complex surfaces that are difficult to automatically scan, like elbows, tees, reducers, inlets, areas around supports, and taps. Some of these other surfaces are shown in the this video:
youtu.be/0LgNpKfORHI
The R-Series actuator is a modular, lightweight, sealed, and rugged actuator for quickly creating and deploying robot tools for use in outdoor and harsh environments. More information can be found at:
hebirobotics.com/r-series-smart-actuators
Any questions, please contact us at:
info@hebirobotics.com
This video demonstrates the setup, training, and scanning of a pipe elbow using an ultrasonic (UT) thickness probe and an arm that was quickly built of HEBI's R-Series Actuators. The motion is trained by fitting a curved surface a handful of points, and then a dense raster scanning motion is planned and executed along the surface. During the scanning a 3D and unwrapped 2D depth map (C-Scan) is constructed in real time.
The water flowing out of the end of the arm is needed to sonically couple the probe to the surface, like the coupling gel used in a medical ultrasound. The arm itself is lightweight (less than 10 kg) and portable. Since the arm is modular it ca be reconfigured for larger, smaller, or hard-to-reach environments.
The method used to measure and train the surface is general and can be applied to a wide range of complex surfaces that are difficult to automatically scan, like elbows, tees, reducers, inlets, areas around supports, and taps. Some of these other surfaces are shown in the this video:
youtu.be/0LgNpKfORHI
The R-Series actuator is a modular, lightweight, sealed, and rugged actuator for quickly creating and deploying robot tools for use in outdoor and harsh environments. More information can be found at:
hebirobotics.com/r-series-smart-actuators
Any questions, please contact us at:
info@hebirobotics.com