Uploaded February 2018 | Updated September 2026, 50 minutes ago
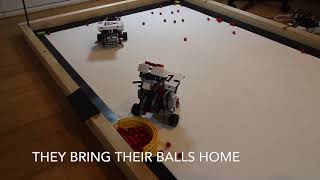
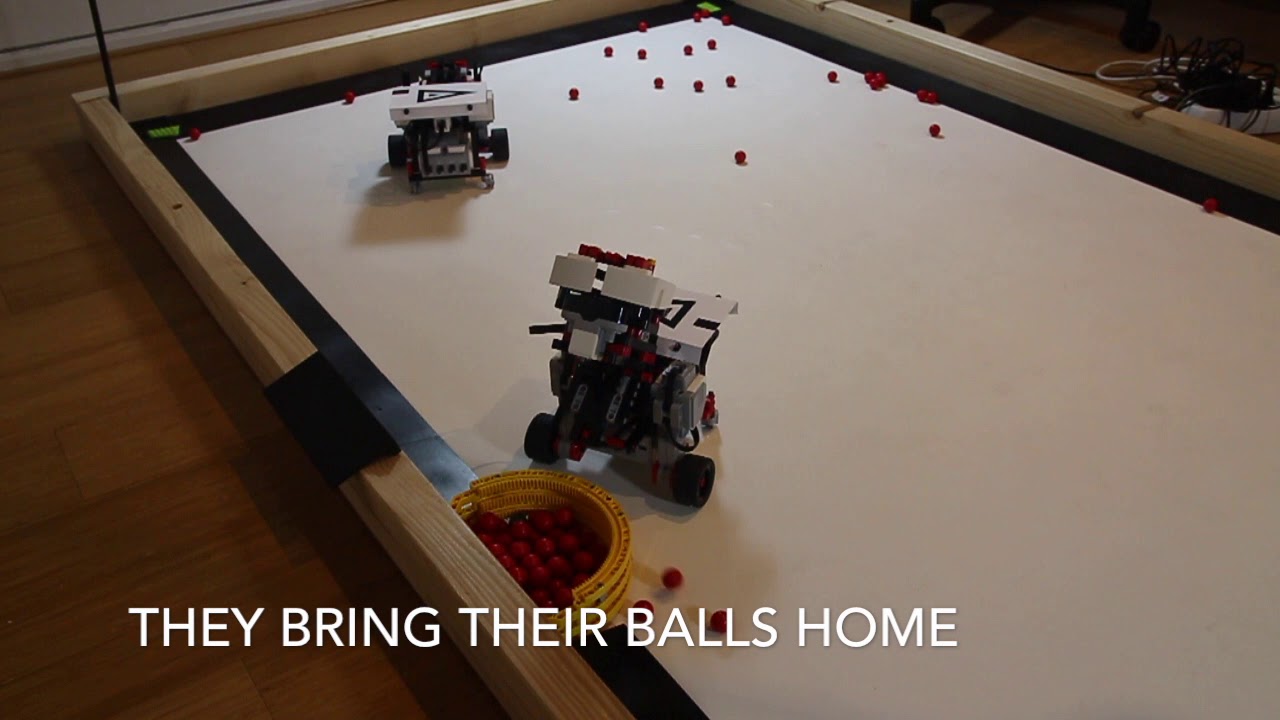
Here is a second version of the the decentralised robot intelligence, with greatly improved ball finding. Here it is built with LEGO Mindstorms Robots. There is a central computer which only relays positions. The robots decide on their own, about 7 times per second, where to go. Their next action depends on their proximity to their neighbours, to the walls and to the contents of their belly. :)
Here is a second version of the the decentralised robot intelligence, with greatly improved ball finding. Here it is built with LEGO Mindstorms Robots. There is a central computer which only relays positions. The robots decide on their own, about 7 times per second, where to go. Their next action depends on their proximity to their neighbours, to the walls and to the contents of their belly. :)