Uploaded May 2018 | Updated September 2026, 2 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Wed PM Pod S.3
Authors: Ramaithitima, Rattanachai; Bhattacharya, Subhrajit
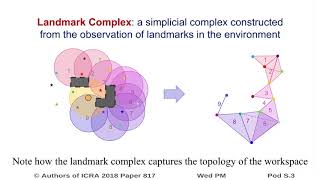
Title: Landmark-Based Exploration with Swarm of Resource Constrained Robots
Abstract:
In this paper we consider the problem of autonomous exploration of an unknown, GPS-denied environment using a swarm of robots with very limited resources and limited sensing capabilities. To that end we use a landmark complex, a simplicial complex utilizing an observation of landmarks, as a topological representation of the environment. Each robot is equipped with an omni-directional, limited-range sensor that can identify landmarks in the robots neighborhood. The robots use the bearing angles to the landmarks for local navigation. Given a collection of identifiable landmarks, a landmark complex can then be cumulatively constructed to encapsulate the topological information of the environment. Under the assumption of sufficiently dense landmarks, we propose an exploration and exploitation strategy that guides the swarm of robots to explore an environment using only bearing measurements without any metric information. Lastly, we demonstrate the coordinate-free and localization-free navigation in the environment using the constructed landmark complex.
ICRA 2018 Spotlight Video
Interactive Session Wed PM Pod S.3
Authors: Ramaithitima, Rattanachai; Bhattacharya, Subhrajit
Title: Landmark-Based Exploration with Swarm of Resource Constrained Robots
Abstract:
In this paper we consider the problem of autonomous exploration of an unknown, GPS-denied environment using a swarm of robots with very limited resources and limited sensing capabilities. To that end we use a landmark complex, a simplicial complex utilizing an observation of landmarks, as a topological representation of the environment. Each robot is equipped with an omni-directional, limited-range sensor that can identify landmarks in the robots neighborhood. The robots use the bearing angles to the landmarks for local navigation. Given a collection of identifiable landmarks, a landmark complex can then be cumulatively constructed to encapsulate the topological information of the environment. Under the assumption of sufficiently dense landmarks, we propose an exploration and exploitation strategy that guides the swarm of robots to explore an environment using only bearing measurements without any metric information. Lastly, we demonstrate the coordinate-free and localization-free navigation in the environment using the constructed landmark complex.