Uploaded May 2018 | Updated September 2026, 2 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Wed PM Pod K.5
Authors: Cruz-Maya, Arturo; Tapus, Adriana
Title: Negotiating with a Robot: Analysis of Regulatory Focus Behavior
Abstract:
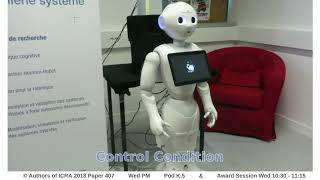
Companion robots are supposed to take the role of caregivers for elderly people, in such scenario, they could face reluctance by the part of their users to do the tasks the robots suggest them to do. In this type of cases, a subtle persuasion could be needed. A social psychology theory called Regulatory Focus states that people have one of two inclinations when taking decisions: Promotion or Prevention Focus. Also, based on these inclinations, people can be influenced by the way the message is sent, including the speed of the speech and the amplitude of body gestures. In this work, we analyze the influence of Regulatory Focus on a negotiation scenario, using 3 conditions: 1) A robot with a promotion behavior, 2) A robot with a prevention behavior, and 3) a robot with a neutral behavior. Results support the psychology theory, suggesting that Promotion participants were more influenced by the robot showing a Promotion based behavior. Also, Prevention participants were more relaxed on the condition with the robot showing a Prevention based behavior, and presented the biggest concession between the initial offer and the final offer.
ICRA 2018 Spotlight Video
Interactive Session Wed PM Pod K.5
Authors: Cruz-Maya, Arturo; Tapus, Adriana
Title: Negotiating with a Robot: Analysis of Regulatory Focus Behavior
Abstract:
Companion robots are supposed to take the role of caregivers for elderly people, in such scenario, they could face reluctance by the part of their users to do the tasks the robots suggest them to do. In this type of cases, a subtle persuasion could be needed. A social psychology theory called Regulatory Focus states that people have one of two inclinations when taking decisions: Promotion or Prevention Focus. Also, based on these inclinations, people can be influenced by the way the message is sent, including the speed of the speech and the amplitude of body gestures. In this work, we analyze the influence of Regulatory Focus on a negotiation scenario, using 3 conditions: 1) A robot with a promotion behavior, 2) A robot with a prevention behavior, and 3) a robot with a neutral behavior. Results support the psychology theory, suggesting that Promotion participants were more influenced by the robot showing a Promotion based behavior. Also, Prevention participants were more relaxed on the condition with the robot showing a Prevention based behavior, and presented the biggest concession between the initial offer and the final offer.