Uploaded May 2018 | Updated September 2026, 2 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Wed AM Pod L.6
Authors: Schwarz, Max; Lenz, Christian; Martin Garcia, German; Koo, Seongyong; Periyasamy, Arul Selvam; Schreiber, Michael; Behnke, Sven
Title: Fast Object Learning and Dual-Arm Coordination for Cluttered Stowing, Picking, and Packing
Abstract:
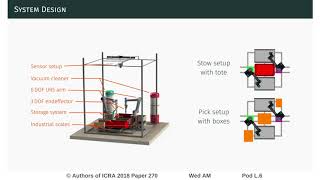
Robotic picking from cluttered bins is a demanding task, for which Amazon Robotics holds challenges. The 2017 Amazon Robotics Challenge (ARC) required stowing items into a storage system, picking specific items, and packing them into boxes. In this paper, we describe the entry of team NimbRo Picking. Our deep object perception pipeline can be quickly and efficiently adapted to new items using a custom turntable capture system and transfer learning. It produces high-quality item segments, on which grasp poses are found. A planning component coordinates manipulation actions between two robot arms, minimizing execution time. The system has been demonstrated successfully at ARC, where our team reached second places in both the picking task and the final stow-and-pick task. We also evaluate individual components.
ICRA 2018 Spotlight Video
Interactive Session Wed AM Pod L.6
Authors: Schwarz, Max; Lenz, Christian; Martin Garcia, German; Koo, Seongyong; Periyasamy, Arul Selvam; Schreiber, Michael; Behnke, Sven
Title: Fast Object Learning and Dual-Arm Coordination for Cluttered Stowing, Picking, and Packing
Abstract:
Robotic picking from cluttered bins is a demanding task, for which Amazon Robotics holds challenges. The 2017 Amazon Robotics Challenge (ARC) required stowing items into a storage system, picking specific items, and packing them into boxes. In this paper, we describe the entry of team NimbRo Picking. Our deep object perception pipeline can be quickly and efficiently adapted to new items using a custom turntable capture system and transfer learning. It produces high-quality item segments, on which grasp poses are found. A planning component coordinates manipulation actions between two robot arms, minimizing execution time. The system has been demonstrated successfully at ARC, where our team reached second places in both the picking task and the final stow-and-pick task. We also evaluate individual components.