Uploaded May 2018 | Updated November 2026, 2 days ago
ICRA 2018 Spotlight Video
Interactive Session Tue AM Pod R.5
Authors: Porav, Horia; Maddern, Will; Newman, Paul
Title: Adversarial Training for Adverse Conditions: Robust Metric Localisation Using Appearance Transfer
Abstract:
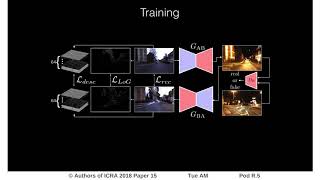
We present a method of improving visual place recognition and metric localisation under very strong appearance change. We learn an invertable generator that can transform the conditions of images, e.g. from day to night, summer to winter etc. This image transforming filter is explicitly designed to aid and abet feature-matching using a new loss based on SURF detector and dense descriptor maps. A network is trained to output synthetic images, features and descriptors given only an input RGB image, and these generated outputs are used to localize the robot against a previously built map using traditional sparse matching approaches. We benchmark our results using multiple traversals of the Oxford RobotCar Dataset over a year-long period, using one traversal as a map and the other to localise. We show that this method significantly improves place recognition and localisation under changing and adverse conditions, while reducing the number of mapping runs needed to successfully achieve reliable localisation.
ICRA 2018 Spotlight Video
Interactive Session Tue AM Pod R.5
Authors: Porav, Horia; Maddern, Will; Newman, Paul
Title: Adversarial Training for Adverse Conditions: Robust Metric Localisation Using Appearance Transfer
Abstract:
We present a method of improving visual place recognition and metric localisation under very strong appearance change. We learn an invertable generator that can transform the conditions of images, e.g. from day to night, summer to winter etc. This image transforming filter is explicitly designed to aid and abet feature-matching using a new loss based on SURF detector and dense descriptor maps. A network is trained to output synthetic images, features and descriptors given only an input RGB image, and these generated outputs are used to localize the robot against a previously built map using traditional sparse matching approaches. We benchmark our results using multiple traversals of the Oxford RobotCar Dataset over a year-long period, using one traversal as a map and the other to localise. We show that this method significantly improves place recognition and localisation under changing and adverse conditions, while reducing the number of mapping runs needed to successfully achieve reliable localisation.