Uploaded July 2017 | Updated September 2026, 2 weeks ago
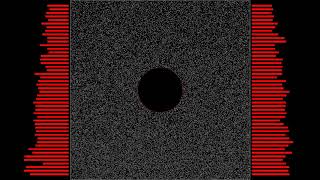
Second video showing the inverse extrinsic calibration procedure, where it is now the 3D camera that is rigidly attached to a tracked object, and the calibration disk is at a fixed position in world space. This setup could, for example, be used to record more dynamic mixed-reality footage of a VR application with a moving camera.
The calibration procedure is very similar, only that now the camera needs to be aimed at the calibration disk from a variety of positions and orientations.
More information:
doc-ok.org/?p=1623
http://idav.ucdavis.edu/~okreylos/ResDev/Kinect
http://idav.ucdavis.edu/~okreylos/ResDev/Vrui
Second video showing the inverse extrinsic calibration procedure, where it is now the 3D camera that is rigidly attached to a tracked object, and the calibration disk is at a fixed position in world space. This setup could, for example, be used to record more dynamic mixed-reality footage of a VR application with a moving camera.
The calibration procedure is very similar, only that now the camera needs to be aimed at the calibration disk from a variety of positions and orientations.
More information:
doc-ok.org/?p=1623
http://idav.ucdavis.edu/~okreylos/ResDev/Kinect
http://idav.ucdavis.edu/~okreylos/ResDev/Vrui