Uploaded November 2014 | Updated November 2026, 2 days ago
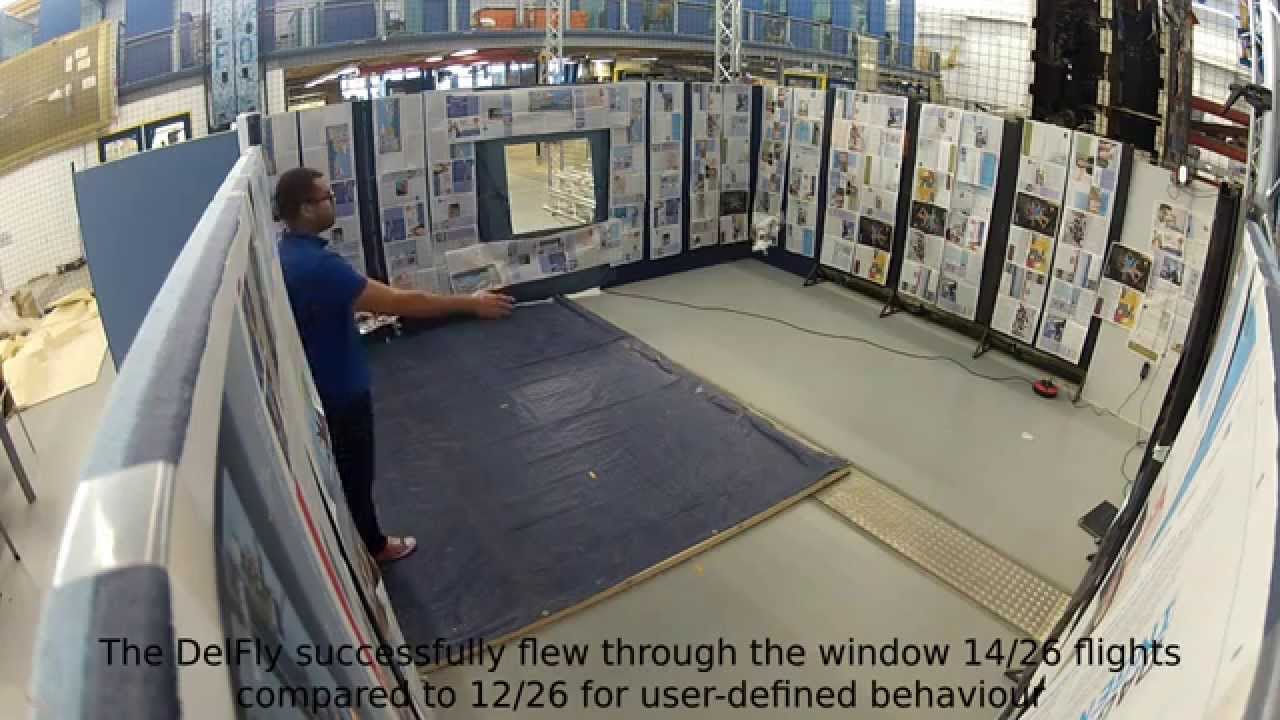
In this experiment, the DelFly Explorer flies around in a room, detects a window, and then flies through it, all with onboard systems (a 1-gram autopilot and 4-gram stereo vision system).
Artificial evolution has optimized a behavior tree controller to achieve this behavior in simulation. It is the first time a behavior tree is used in such an evolutionary robotics setup. The motivation is that a behavior tree can be easily understood by the human experimenter and can hence be adapted manually to suit the robot in the real world.
Msc Thesis: http://repository.tudelft.nl/view/ir/uuid%3Adde8d42e-590a-465d-abaf-760ec304760f/
Self-archived journal submission: arxiv.org/abs/1411.7267
Music: "Revolve" by cinematrik CC BY 1.0
ccmixter.org/files/hisboyelroy/430
In this experiment, the DelFly Explorer flies around in a room, detects a window, and then flies through it, all with onboard systems (a 1-gram autopilot and 4-gram stereo vision system).
Artificial evolution has optimized a behavior tree controller to achieve this behavior in simulation. It is the first time a behavior tree is used in such an evolutionary robotics setup. The motivation is that a behavior tree can be easily understood by the human experimenter and can hence be adapted manually to suit the robot in the real world.
Msc Thesis: http://repository.tudelft.nl/view/ir/uuid%3Adde8d42e-590a-465d-abaf-760ec304760f/
Self-archived journal submission: arxiv.org/abs/1411.7267
Music: "Revolve" by cinematrik CC BY 1.0
ccmixter.org/files/hisboyelroy/430