Uploaded July 2024 | Updated November 2026, 3 hours ago
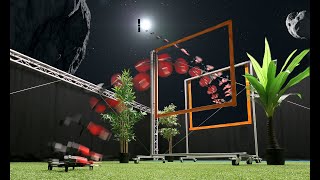
MAVLab TUDelft - ESA Advanced Concepts Team
Our work can be found in the following publications:
doi.org/10.1126/scirobotics.adi6421 - Optimality principles in spacecraft neural guidance and control
doi.org/10.1016/j.robot.2023.104588 - End-to-end Neural Network Based Quadcopter control
arxiv.org/abs/2305.02705 - Guidance & Control Networks for Time-Optimal Quadcopter Flight
arxiv.org/abs/2311.16948 - End-to-end Reinforcement Learning for Time-Optimal Quadcopter Flight
linkedin.com/posts/cdewagter_space-drones-autonomous-activity-7211121330040037377-Uora?utm_source=combined_share_message&utm_medium=member_android
MAVLab TUDelft - ESA Advanced Concepts Team
Our work can be found in the following publications:
doi.org/10.1126/scirobotics.adi6421 - Optimality principles in spacecraft neural guidance and control
doi.org/10.1016/j.robot.2023.104588 - End-to-end Neural Network Based Quadcopter control
arxiv.org/abs/2305.02705 - Guidance & Control Networks for Time-Optimal Quadcopter Flight
arxiv.org/abs/2311.16948 - End-to-end Reinforcement Learning for Time-Optimal Quadcopter Flight
linkedin.com/posts/cdewagter_space-drones-autonomous-activity-7211121330040037377-Uora?utm_source=combined_share_message&utm_medium=member_android