Uploaded September 2018 | Updated November 2026, 3 hours ago
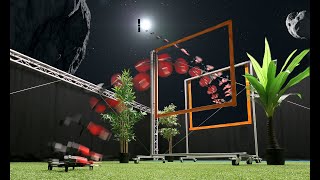
The DelFly Nimble is a novel flapping wing robot with exceptional flight characteristics, developed at TU Delft. Thanks to its nimble flight capabilities it is even able to mimic rapid maneuvers as performed by insects. Together with the Experimental Zoology Group at Wageningen UR, we studied these maneuvers in a systematic way, giving new insights into insect flight.
More details on the robot, and its use in studying fruit-fly escape maneuvers, can be found in the following scientific article:
Matěj Karásek, Florian T. Muijres, Christophe De Wagter, Bart D.W. Remes, Guido C.H.E. de Croon: A tailless aerial robotic flapper reveals that flies use torque coupling in rapid banked turns. Science, Vol 361, Iss 6407, 2018. DOI: 10.1126/science.aat0350
science.sciencemag.org/cgi/doi/10.1126/science.aat0350
This research is a collaboration between the Micro Air Vehicle Lab at TU Delft (http://mavlab.tudelft.nl) and the Experimental Zoology Group at Wageningen UR (http://www.wur.nl/ezo).
We greatly appreciate the support of the TU Delft Robotics Institute:
https://tudelftroboticsinstitute.nl/
For other flapping-wing robots developed at MAVLab, TU Delft, check:
http://www.delfly.nl
The DelFly Nimble is a novel flapping wing robot with exceptional flight characteristics, developed at TU Delft. Thanks to its nimble flight capabilities it is even able to mimic rapid maneuvers as performed by insects. Together with the Experimental Zoology Group at Wageningen UR, we studied these maneuvers in a systematic way, giving new insights into insect flight.
More details on the robot, and its use in studying fruit-fly escape maneuvers, can be found in the following scientific article:
Matěj Karásek, Florian T. Muijres, Christophe De Wagter, Bart D.W. Remes, Guido C.H.E. de Croon: A tailless aerial robotic flapper reveals that flies use torque coupling in rapid banked turns. Science, Vol 361, Iss 6407, 2018. DOI: 10.1126/science.aat0350
science.sciencemag.org/cgi/doi/10.1126/science.aat0350
This research is a collaboration between the Micro Air Vehicle Lab at TU Delft (http://mavlab.tudelft.nl) and the Experimental Zoology Group at Wageningen UR (http://www.wur.nl/ezo).
We greatly appreciate the support of the TU Delft Robotics Institute:
https://tudelftroboticsinstitute.nl/
For other flapping-wing robots developed at MAVLab, TU Delft, check:
http://www.delfly.nl