Uploaded April 2023 | Updated November 2026, 43 minutes ago
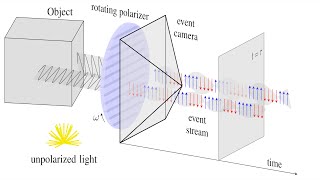
State-of-the-art solutions for Shape-from-Polarization (SfP) suffer from a speed-resolution tradeoff: they either sacrifice the number of polarization angles measured or necessitate lengthy acquisition times due to framerate constraints, thus compromising either accuracy or latency. We tackle this tradeoff using event cameras. Event cameras operate at microseconds resolution with negligible motion blur, and output a continuous stream of events that precisely measures how light changes over time asynchronously. We propose a setup that consists of a linear polarizer rotating at high speeds in front of an event camera. Our method uses the continuous event stream caused by the rotation to reconstruct relative intensities at multiple polarizer angles. Experiments demonstrate that our method outperforms physics-based baselines using frames, reducing the MAE by 25% in synthetic and real-world datasets. In the real world, we observe, however, that the challenging conditions (i.e., when few events are generated) harm the performance of physics-based solutions. To overcome this, we propose a learning-based approach that learns to estimate surface normals even at low event-rates, improving the physics-based approach by 52% on the real world dataset. The proposed system achieves an acquisition speed equivalent to 50 fps (more than twice the framerate of the commercial polarization sensor) while retaining the spatial resolution of 1MP. Our evaluation is based on the first large-scale dataset for event-based SfP. Code and dataset is available at https://rpg.ifi.uzh.ch/esfp.html
Reference:
Manasi Muglikar, Leonard Bauersfeld, Diederik P. Moeys, Davide Scaramuzza
Event-based Shape from Polarization
PDF: https://rpg.ifi.uzh.ch/docs/CVPR23_Muglikar.pdf
Code: https://rpg.ifi.uzh.ch/esfp.html
Our research page on event-based vision: http://rpg.ifi.uzh.ch/research_dvs.html
For an event camera simulator: http://rpg.ifi.uzh.ch/esim
For a survey paper on event cameras, see here: https://rpg.ifi.uzh.ch/docs/EventVisionSurvey.pdf
Other resources on event cameras (publications, software, drivers, where to buy, etc.): github.com/uzh-rpg/event-based_vision_resources
Affiliation:
D. Moeys is with Advanced Sensors and Modelling Group, SONY R&D Center Europe, SL1
M.Muglikar, L. Bauersfeld, D. Scaramuzza are with the Robotics and Perception Group, Dept. of Informatics, University of Zurich, and Dept. of Neuroinformatics, University of Zurich and ETH Zurich, Switzerland http://rpg.ifi.uzh.ch/
State-of-the-art solutions for Shape-from-Polarization (SfP) suffer from a speed-resolution tradeoff: they either sacrifice the number of polarization angles measured or necessitate lengthy acquisition times due to framerate constraints, thus compromising either accuracy or latency. We tackle this tradeoff using event cameras. Event cameras operate at microseconds resolution with negligible motion blur, and output a continuous stream of events that precisely measures how light changes over time asynchronously. We propose a setup that consists of a linear polarizer rotating at high speeds in front of an event camera. Our method uses the continuous event stream caused by the rotation to reconstruct relative intensities at multiple polarizer angles. Experiments demonstrate that our method outperforms physics-based baselines using frames, reducing the MAE by 25% in synthetic and real-world datasets. In the real world, we observe, however, that the challenging conditions (i.e., when few events are generated) harm the performance of physics-based solutions. To overcome this, we propose a learning-based approach that learns to estimate surface normals even at low event-rates, improving the physics-based approach by 52% on the real world dataset. The proposed system achieves an acquisition speed equivalent to 50 fps (more than twice the framerate of the commercial polarization sensor) while retaining the spatial resolution of 1MP. Our evaluation is based on the first large-scale dataset for event-based SfP. Code and dataset is available at https://rpg.ifi.uzh.ch/esfp.html
Reference:
Manasi Muglikar, Leonard Bauersfeld, Diederik P. Moeys, Davide Scaramuzza
Event-based Shape from Polarization
PDF: https://rpg.ifi.uzh.ch/docs/CVPR23_Muglikar.pdf
Code: https://rpg.ifi.uzh.ch/esfp.html
Our research page on event-based vision: http://rpg.ifi.uzh.ch/research_dvs.html
For an event camera simulator: http://rpg.ifi.uzh.ch/esim
For a survey paper on event cameras, see here: https://rpg.ifi.uzh.ch/docs/EventVisionSurvey.pdf
Other resources on event cameras (publications, software, drivers, where to buy, etc.): github.com/uzh-rpg/event-based_vision_resources
Affiliation:
D. Moeys is with Advanced Sensors and Modelling Group, SONY R&D Center Europe, SL1
M.Muglikar, L. Bauersfeld, D. Scaramuzza are with the Robotics and Perception Group, Dept. of Informatics, University of Zurich, and Dept. of Neuroinformatics, University of Zurich and ETH Zurich, Switzerland http://rpg.ifi.uzh.ch/