Uploaded May 2021 | Updated November 2026, 2 hours ago
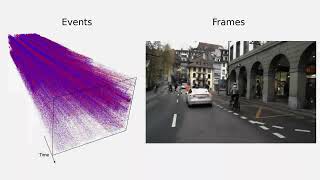
Once an academic venture, autonomous driving has received unparalleled corporate funding in the last decade. Still, the operating conditions of current autonomous cars are mostly restricted to ideal scenarios. This means that driving in challenging illumination conditions such as night, sunrise, and sunset remains an open problem. In these cases, standard cameras are being pushed to their limits in terms of low light and high dynamic range performance. To address these challenges, we propose, DSEC, a new dataset that contains such demanding illumination conditions and provides a rich set of sensory data. DSEC offers data from a wide-baseline stereo setup of two color frame cameras and two high-resolution monochrome event cameras. In addition, we collect lidar data and RTK GPS measurements, both hardware synchronized with all camera data. One of the distinctive features of this dataset is the inclusion of high-resolution event cameras. Event cameras have received increasing attention for their high temporal resolution and high dynamic range performance. However, due to their novelty, event camera datasets in driving scenarios are rare. This work presents the first high-resolution, large-scale stereo dataset with event cameras. The dataset contains 53 sequences collected by driving in a variety of illumination conditions and provides ground truth disparity for the development and evaluation of event-based stereo algorithms.
DSEC webpage: https://dsec.ifi.uzh.ch
Code: github.com/uzh-rpg/DSEC
Slides: http://rpg.ifi.uzh.ch/dsec/icra21_slides.pptx
Reference paper:
M. Gehrig, W. Aarents, D. Gehrig, D. Scaramuzza
"DSEC: A Stereo Event Camera Dataset for Driving Scenarios"
IEEE Robotics and Automation Letters, 2021
PDF: http://rpg.ifi.uzh.ch/docs/RAL21_DSEC.pdf
For more information about our research, visit these pages:
1. Event-based Vision: http://rpg.ifi.uzh.ch/research_dvs.html
2. Machine Learning: http://rpg.ifi.uzh.ch/research_learning.html
Affiliations:
M. Gehrig, W. Aarents, D. Gehrig, D. Scaramuzza are with the Robotics and Perception Group, Dep. of Informatics, University of Zurich, and Dep. of Neuroinformatics, University of Zurich and ETH Zurich, Switzerland.
Once an academic venture, autonomous driving has received unparalleled corporate funding in the last decade. Still, the operating conditions of current autonomous cars are mostly restricted to ideal scenarios. This means that driving in challenging illumination conditions such as night, sunrise, and sunset remains an open problem. In these cases, standard cameras are being pushed to their limits in terms of low light and high dynamic range performance. To address these challenges, we propose, DSEC, a new dataset that contains such demanding illumination conditions and provides a rich set of sensory data. DSEC offers data from a wide-baseline stereo setup of two color frame cameras and two high-resolution monochrome event cameras. In addition, we collect lidar data and RTK GPS measurements, both hardware synchronized with all camera data. One of the distinctive features of this dataset is the inclusion of high-resolution event cameras. Event cameras have received increasing attention for their high temporal resolution and high dynamic range performance. However, due to their novelty, event camera datasets in driving scenarios are rare. This work presents the first high-resolution, large-scale stereo dataset with event cameras. The dataset contains 53 sequences collected by driving in a variety of illumination conditions and provides ground truth disparity for the development and evaluation of event-based stereo algorithms.
DSEC webpage: https://dsec.ifi.uzh.ch
Code: github.com/uzh-rpg/DSEC
Slides: http://rpg.ifi.uzh.ch/dsec/icra21_slides.pptx
Reference paper:
M. Gehrig, W. Aarents, D. Gehrig, D. Scaramuzza
"DSEC: A Stereo Event Camera Dataset for Driving Scenarios"
IEEE Robotics and Automation Letters, 2021
PDF: http://rpg.ifi.uzh.ch/docs/RAL21_DSEC.pdf
For more information about our research, visit these pages:
1. Event-based Vision: http://rpg.ifi.uzh.ch/research_dvs.html
2. Machine Learning: http://rpg.ifi.uzh.ch/research_learning.html
Affiliations:
M. Gehrig, W. Aarents, D. Gehrig, D. Scaramuzza are with the Robotics and Perception Group, Dep. of Informatics, University of Zurich, and Dep. of Neuroinformatics, University of Zurich and ETH Zurich, Switzerland.