Uploaded October 2025 | Updated November 2026, 11 hours ago
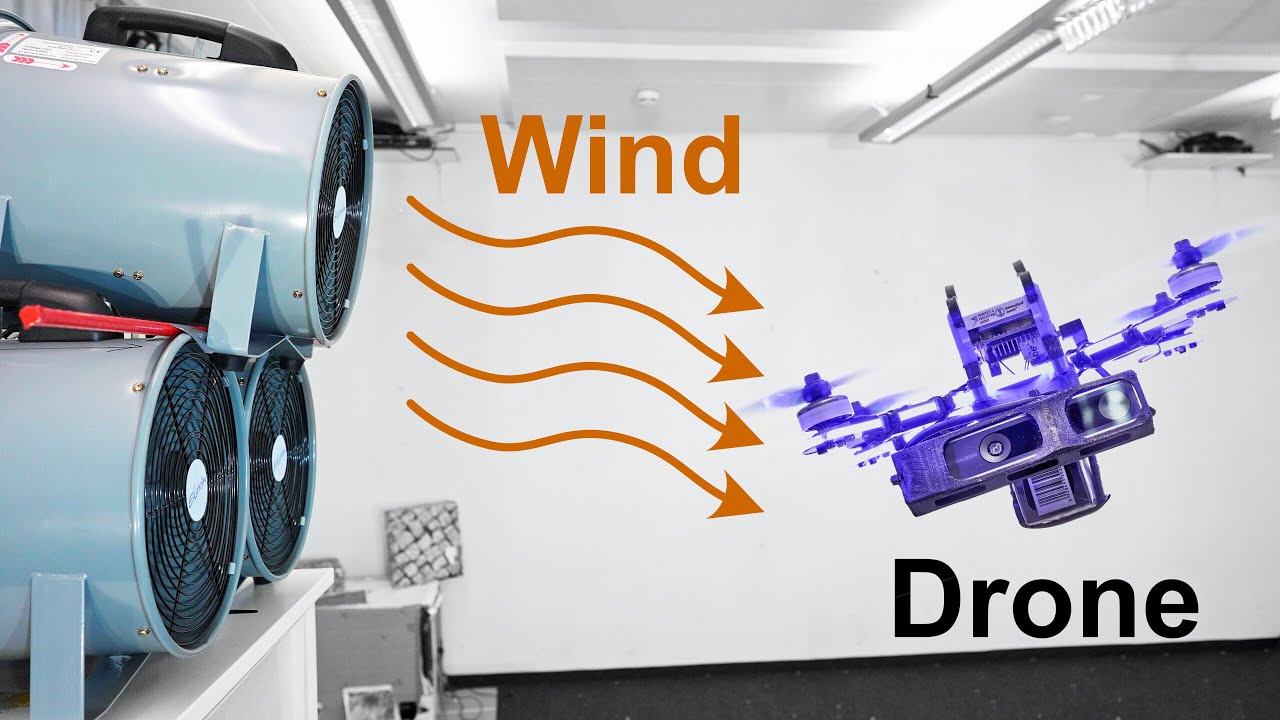
Visual-inertial odometry (VIO) is widely used for state estimation in autonomous micro aerial vehicles using on-board sensors. Current methods improve VIO by incorporating a model of the translational vehicle dynamics, yet their performance degrades when faced with low-accuracy vehicle models or continuous external disturbances, like wind. Additionally, incorporating rotational dynamics in these models is computationally intractable when they are deployed in online applications, e.g., in a closed-loop control system. We present HDVIO2.0, which models full 6-DoF, translational and rotational, vehicle dynamics and tightly incorporates them into a VIO system with minimal impact on the runtime. HDVIO2.0 builds upon the previous work, HDVIO, and addresses these challenges through a hybrid dynamics model combining a point-mass vehicle model with a learning based component, with access to control commands and IMU history, to capture complex aerodynamic effects. The key idea behind modeling the rotational dynamics is to represent them with continuous-time functions. HDVIO2.0 leverages the divergence between the actual motion and the predicted motion from the hybrid dynamics model to estimate external forces as well as the robot state. Our system surpasses the performance of state-of-the-art methods in experiments using public and new drone dynamics datasets, as well as real-world flights in winds up to 25 km/h. Unlike existing approaches, we also show that accurate vehicle dynamics predictions are achievable without precise knowledge of the vehicle state.
Reference:
Giovanni Cioffi, Leonard Bauersfeld, Davide Scaramuzza
HDVIO2.0: Wind and Disturbance Estimation with Hybrid Dynamics VIO
Transactions on Robotics (T-RO) 2025
PDF: https://rpg.ifi.uzh.ch/docs/tro25_Cioffi.pdf
Code: github.com/uzh-rpg/hdvio2.0
Our research page on visual-inertial odometry: https://rpg.ifi.uzh.ch/research_vo.html
Our research page on agile drone flight: https://rpg.ifi.uzh.ch/aggressive_fli...
Our research page on vision-based drone navigation: https://rpg.ifi.uzh.ch/research_mav.html
Affiliation:
Giovanni Cioffi, Leonard Bauersfeld, and D. Scaramuzza are with the Robotics and Perception Group, Dept. of Informatics, University of Zurich, and Dept. of Neuroinformatics, University of Zurich and ETH Zurich, Switzerland https://rpg.ifi.uzh.ch/
Visual-inertial odometry (VIO) is widely used for state estimation in autonomous micro aerial vehicles using on-board sensors. Current methods improve VIO by incorporating a model of the translational vehicle dynamics, yet their performance degrades when faced with low-accuracy vehicle models or continuous external disturbances, like wind. Additionally, incorporating rotational dynamics in these models is computationally intractable when they are deployed in online applications, e.g., in a closed-loop control system. We present HDVIO2.0, which models full 6-DoF, translational and rotational, vehicle dynamics and tightly incorporates them into a VIO system with minimal impact on the runtime. HDVIO2.0 builds upon the previous work, HDVIO, and addresses these challenges through a hybrid dynamics model combining a point-mass vehicle model with a learning based component, with access to control commands and IMU history, to capture complex aerodynamic effects. The key idea behind modeling the rotational dynamics is to represent them with continuous-time functions. HDVIO2.0 leverages the divergence between the actual motion and the predicted motion from the hybrid dynamics model to estimate external forces as well as the robot state. Our system surpasses the performance of state-of-the-art methods in experiments using public and new drone dynamics datasets, as well as real-world flights in winds up to 25 km/h. Unlike existing approaches, we also show that accurate vehicle dynamics predictions are achievable without precise knowledge of the vehicle state.
Reference:
Giovanni Cioffi, Leonard Bauersfeld, Davide Scaramuzza
HDVIO2.0: Wind and Disturbance Estimation with Hybrid Dynamics VIO
Transactions on Robotics (T-RO) 2025
PDF: https://rpg.ifi.uzh.ch/docs/tro25_Cioffi.pdf
Code: github.com/uzh-rpg/hdvio2.0
Our research page on visual-inertial odometry: https://rpg.ifi.uzh.ch/research_vo.html
Our research page on agile drone flight: https://rpg.ifi.uzh.ch/aggressive_fli...
Our research page on vision-based drone navigation: https://rpg.ifi.uzh.ch/research_mav.html
Affiliation:
Giovanni Cioffi, Leonard Bauersfeld, and D. Scaramuzza are with the Robotics and Perception Group, Dept. of Informatics, University of Zurich, and Dept. of Neuroinformatics, University of Zurich and ETH Zurich, Switzerland https://rpg.ifi.uzh.ch/