Uploaded December 2019 | Updated November 2026, 47 minutes ago
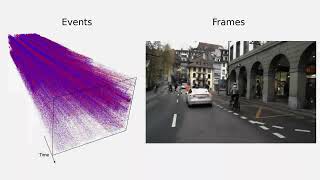
Event cameras are novel sensors that output brightness changes in the form of a stream of asynchronous "events" instead of intensity frames. They offer significant advantages with respect to conventional cameras: High Dynamic Range (HDR), high temporal resolution, and no motion blur.
Recently, novel learning approaches operating on event data have achieved impressive results. Yet, these methods require a large amount of event data for training, which is hardly available due the novelty of event sensors in computer vision research. In this work, we present a method that addresses these needs by converting any existing video dataset recorded with conventional cameras to synthetic event data. This unlocks the use of a virtually unlimited number of existing video datasets for training networks designed for real event data. We evaluate our method on two relevant vision tasks, i.e., object recognition and semantic segmentation, and show that models trained on synthetic events have several benefits:
(i) they generalize well to real event data, even in scenarios where standard-camera images are blurry or overexposed, by inheriting the outstanding properties of event cameras;
(ii) they can be used for fine-tuning on real data to improve over state-of-the-art for both classification and semantic segmentation.
Reference:
Daniel Gehrig, Mathias Gehrig, Javier Hidalgo-Carrió, Davide Scaramuzza.
Video to Events: Bringing Modern Computer Vision Closer to Event Cameras
IEEE Conference on Computer Vision and Pattern Recognition (CVPR), Seattle, 2020
PDF: http://rpg.ifi.uzh.ch/docs/CVPR20_Gehrig.pdf
Code: github.com/uzh-rpg/rpg_vid2e
Our research page on event based vision: http://rpg.ifi.uzh.ch/research_dvs.html
For event-camera datasets, see here:
http://rpg.ifi.uzh.ch/davis_data.html
and here: github.com/uzh-rpg/event-based_vision_resources#datasets
For an event camera simulator: http://rpg.ifi.uzh.ch/esim/index.html
For a survey paper on event cameras, see here:
http://rpg.ifi.uzh.ch/docs/EventVisionSurvey.pdf
Other resources on event cameras (publications, software, drivers, where to buy, etc.):
github.com/uzh-rpg/event-based_vision_resources
Affiliation:
D. Gehrig, M. Gehrig, J. Hidalgo-Carrió and D. Scaramuzza are with the Robotics and Perception Group, Dept. of Informatics, University of Zurich, and Dept. of Neuroinformatics, University of Zurich and ETH Zurich, Switzerland http://rpg.ifi.uzh.ch/
Event cameras are novel sensors that output brightness changes in the form of a stream of asynchronous "events" instead of intensity frames. They offer significant advantages with respect to conventional cameras: High Dynamic Range (HDR), high temporal resolution, and no motion blur.
Recently, novel learning approaches operating on event data have achieved impressive results. Yet, these methods require a large amount of event data for training, which is hardly available due the novelty of event sensors in computer vision research. In this work, we present a method that addresses these needs by converting any existing video dataset recorded with conventional cameras to synthetic event data. This unlocks the use of a virtually unlimited number of existing video datasets for training networks designed for real event data. We evaluate our method on two relevant vision tasks, i.e., object recognition and semantic segmentation, and show that models trained on synthetic events have several benefits:
(i) they generalize well to real event data, even in scenarios where standard-camera images are blurry or overexposed, by inheriting the outstanding properties of event cameras;
(ii) they can be used for fine-tuning on real data to improve over state-of-the-art for both classification and semantic segmentation.
Reference:
Daniel Gehrig, Mathias Gehrig, Javier Hidalgo-Carrió, Davide Scaramuzza.
Video to Events: Bringing Modern Computer Vision Closer to Event Cameras
IEEE Conference on Computer Vision and Pattern Recognition (CVPR), Seattle, 2020
PDF: http://rpg.ifi.uzh.ch/docs/CVPR20_Gehrig.pdf
Code: github.com/uzh-rpg/rpg_vid2e
Our research page on event based vision: http://rpg.ifi.uzh.ch/research_dvs.html
For event-camera datasets, see here:
http://rpg.ifi.uzh.ch/davis_data.html
and here: github.com/uzh-rpg/event-based_vision_resources#datasets
For an event camera simulator: http://rpg.ifi.uzh.ch/esim/index.html
For a survey paper on event cameras, see here:
http://rpg.ifi.uzh.ch/docs/EventVisionSurvey.pdf
Other resources on event cameras (publications, software, drivers, where to buy, etc.):
github.com/uzh-rpg/event-based_vision_resources
Affiliation:
D. Gehrig, M. Gehrig, J. Hidalgo-Carrió and D. Scaramuzza are with the Robotics and Perception Group, Dept. of Informatics, University of Zurich, and Dept. of Neuroinformatics, University of Zurich and ETH Zurich, Switzerland http://rpg.ifi.uzh.ch/