Uploaded January 2021 | Updated November 2026, 3 hours ago
We propose a learning process to solve two fundamental problems of optical flow control.
Problems of optical flow control
Flying insects heavily rely on optical flow for visual navigation and flight control. Roboticists have endowed small flying robots with optical flow control as well, since it requires just a tiny vision sensor.
However, when using optical flow, the robots run into two problems that insects appear to have overcome. Firstly, since optical flow only provides mixed information on distances and velocities, using it for control leads to oscillations when getting closer to obstacles. Secondly, since optical flow provides very little information on obstacles in the direction of motion, it is hardest to detect obstacles that the robot is actually going to collide with!
Learning process as a solution
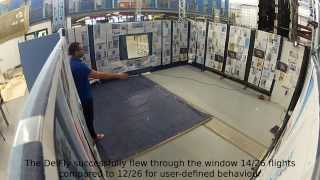
We propose a solution to these problems by means of a learning process. During learning, the robot exploits self-induced oscillations to learn what the objects in its environment look like at different distances. After learning, the robot can perform faster and smoother optical flow landings and fly faster and safer flight in cluttered environments.
Moreover, our solution entails a new hypothesis for insect intelligence. Insect flight control for tasks such as landing or obstacle avoidance is typically described in terms of pre-wired optical flow control laws. Our work suggests that flying insects may learn the visual appearance of their environment to improve their flight and navigation skills over their lifetime.
Read the article at:
- nature.com/articles/s42256-020-00279-7
- doi.org/10.1038/s42256-020-00279-7
We propose a learning process to solve two fundamental problems of optical flow control.
Problems of optical flow control
Flying insects heavily rely on optical flow for visual navigation and flight control. Roboticists have endowed small flying robots with optical flow control as well, since it requires just a tiny vision sensor.
However, when using optical flow, the robots run into two problems that insects appear to have overcome. Firstly, since optical flow only provides mixed information on distances and velocities, using it for control leads to oscillations when getting closer to obstacles. Secondly, since optical flow provides very little information on obstacles in the direction of motion, it is hardest to detect obstacles that the robot is actually going to collide with!
Learning process as a solution
We propose a solution to these problems by means of a learning process. During learning, the robot exploits self-induced oscillations to learn what the objects in its environment look like at different distances. After learning, the robot can perform faster and smoother optical flow landings and fly faster and safer flight in cluttered environments.
Moreover, our solution entails a new hypothesis for insect intelligence. Insect flight control for tasks such as landing or obstacle avoidance is typically described in terms of pre-wired optical flow control laws. Our work suggests that flying insects may learn the visual appearance of their environment to improve their flight and navigation skills over their lifetime.
Read the article at:
- nature.com/articles/s42256-020-00279-7
- doi.org/10.1038/s42256-020-00279-7