Uploaded September 2020 | Updated September 2026, 6 hours ago
The Global Positioning System (GPS) is a crucial component in consumer drones. GPS aided navigation is of straightforward usage. This project investigates the possibilities of drone navigation in case of GPS absence. In particular, our goal is to fly a drone from A to B without using GPS signals but with a camera attached.
The pose estimation of a camera given its image is a well known and difficult computer vision problem. In general, the problem results in the estimation of 6 parameters (degrees of freedom (DoF)) using a trade-off between optimality and performance. The 6 parameters are the position in space: x-,y-,z-coordinate, and an arbitrary orientation.
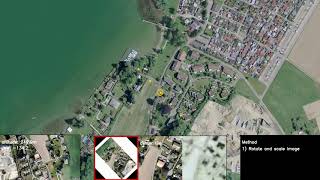
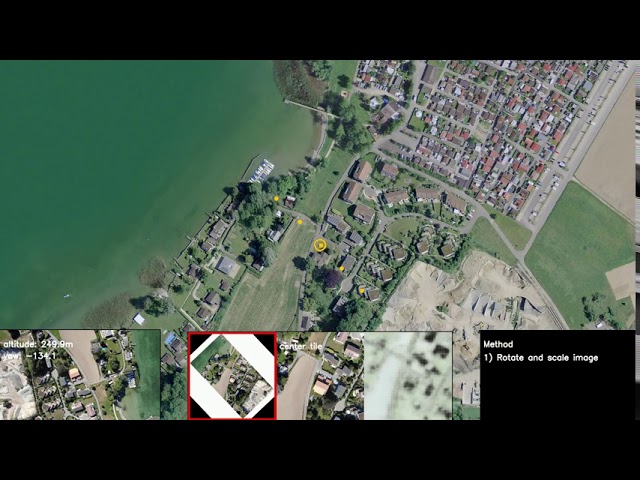
The Swiss Federal Office of Topography, swisstopo, provides to us maps in two styles: an orthographic projection of aerial photographs (referred to as ortho map) and its stripped-down abstractions, well known as the 1:25’000 maps (referred as the abstract map). Our approach to the pose estimation problem is to match the camera image on such a swisstopo map. To improve the matching we apply a learned transformation to the camera image and the map. For more details on the image, transformation learning see the video youtu.be/5JEFe2_L4So
The Global Positioning System (GPS) is a crucial component in consumer drones. GPS aided navigation is of straightforward usage. This project investigates the possibilities of drone navigation in case of GPS absence. In particular, our goal is to fly a drone from A to B without using GPS signals but with a camera attached.
The pose estimation of a camera given its image is a well known and difficult computer vision problem. In general, the problem results in the estimation of 6 parameters (degrees of freedom (DoF)) using a trade-off between optimality and performance. The 6 parameters are the position in space: x-,y-,z-coordinate, and an arbitrary orientation.
The Swiss Federal Office of Topography, swisstopo, provides to us maps in two styles: an orthographic projection of aerial photographs (referred to as ortho map) and its stripped-down abstractions, well known as the 1:25’000 maps (referred as the abstract map). Our approach to the pose estimation problem is to match the camera image on such a swisstopo map. To improve the matching we apply a learned transformation to the camera image and the map. For more details on the image, transformation learning see the video youtu.be/5JEFe2_L4So