Uploaded June 2026 | Updated September 2026, 2 hours ago
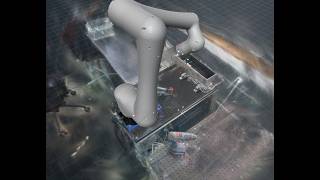
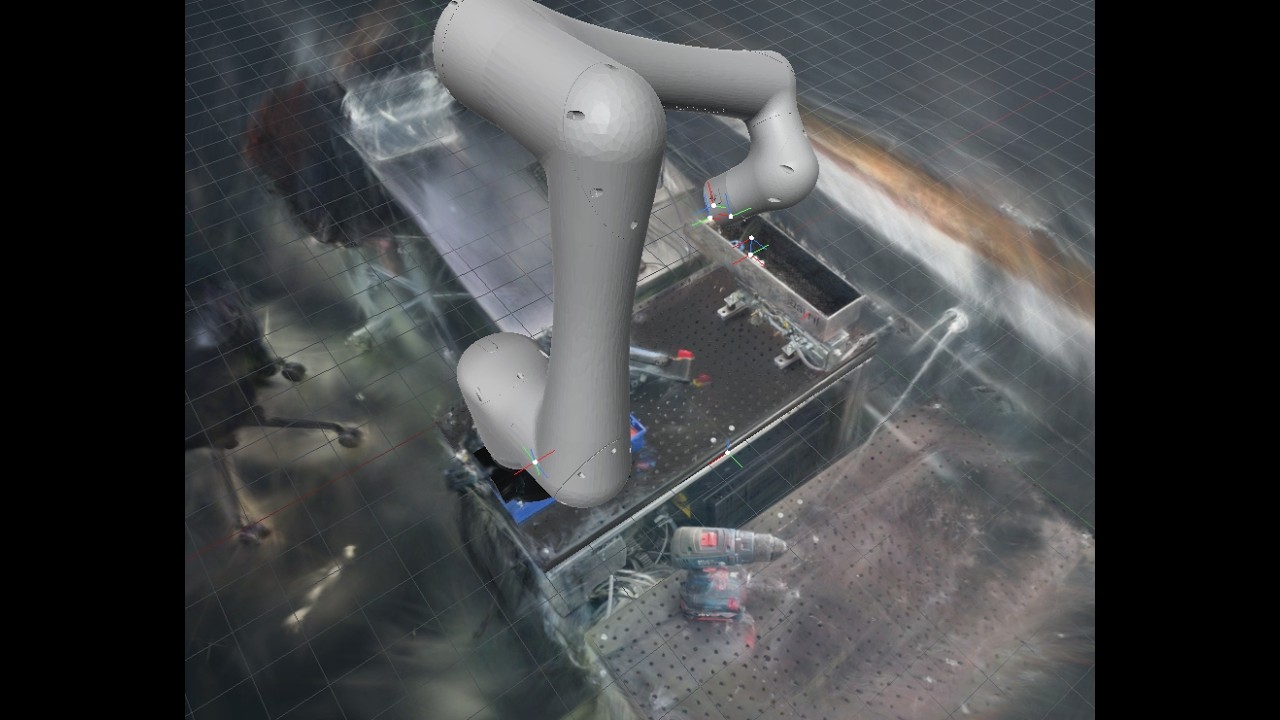
Saf3D automates the reconstruction of a robot’s real work environment as a 3D model for use in a digital twin, using only the camera already mounted on the robot and no additional sensors. While the robot itself is available as a CAD model, its surrounding environment changes between tasks and currently requires manual modeling at Auto-Mate Robotics.
This bachelor thesis investigates whether image-based reconstruction can generate a sufficiently useful representation of the robot work environment for visualization and collision checking. The proposed pipeline moves the robot along a predefined path, captures images and camera poses, reconstructs camera positions and a sparse point cloud using COLMAP Structure-from-Motion, and transforms the result into the robot coordinate system. To improve visual quality, Gaussian Splatting with Brush is used to create a photorealistic 3D scene representation, with optional mesh generation. The resulting models are integrated into the Auto-Mate Robotics digital twin via a gRPC interface.
Saf3D automates the reconstruction of a robot’s real work environment as a 3D model for use in a digital twin, using only the camera already mounted on the robot and no additional sensors. While the robot itself is available as a CAD model, its surrounding environment changes between tasks and currently requires manual modeling at Auto-Mate Robotics.
This bachelor thesis investigates whether image-based reconstruction can generate a sufficiently useful representation of the robot work environment for visualization and collision checking. The proposed pipeline moves the robot along a predefined path, captures images and camera poses, reconstructs camera positions and a sparse point cloud using COLMAP Structure-from-Motion, and transforms the result into the robot coordinate system. To improve visual quality, Gaussian Splatting with Brush is used to create a photorealistic 3D scene representation, with optional mesh generation. The resulting models are integrated into the Auto-Mate Robotics digital twin via a gRPC interface.