Uploaded June 2025 | Updated November 2026, 3 hours ago
aiXiv: arxiv.org/abs/2506.17486
Project page: zacravichandran.github.io/PRISM
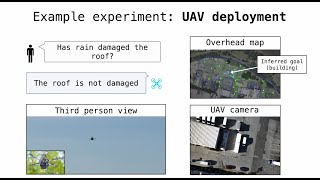
Abstract: Large language models (LLMs) provide robots with powerful contextual reasoning abilities and a natural human interface. Yet, current LLM-enabled robots typically depend on cloud-hosted models, limiting their usability in environments with unreliable communication infrastructure, such as outdoor or industrial settings. We present PRISM, a framework for distilling small language model (SLM)-enabled robot planners that run on-device with minimal human supervision. Starting from an existing LLM-enabled planner, PRISM automatically synthesizes diverse tasks and environments, elicits plans from the LLM, and uses this synthetic dataset to distill a compact SLM as a drop-in replacement of the source model. We apply PRISM to three LLM-enabled planners for mapping and exploration, manipulation, and household assistance, and we demonstrate that PRISM
improves the performance of Llama-3.2-3B from 10-20% of GPT-4o’s performance to over 93% — using only synthetic data. We further demonstrate that the distilled planners generalize across heterogeneous robotic platforms (ground and aerial) and diverse environments (indoor and outdoor). We release all software, trained models, and datasets at zacravichandran.github.io/PRISM.
aiXiv: arxiv.org/abs/2506.17486
Project page: zacravichandran.github.io/PRISM
Abstract: Large language models (LLMs) provide robots with powerful contextual reasoning abilities and a natural human interface. Yet, current LLM-enabled robots typically depend on cloud-hosted models, limiting their usability in environments with unreliable communication infrastructure, such as outdoor or industrial settings. We present PRISM, a framework for distilling small language model (SLM)-enabled robot planners that run on-device with minimal human supervision. Starting from an existing LLM-enabled planner, PRISM automatically synthesizes diverse tasks and environments, elicits plans from the LLM, and uses this synthetic dataset to distill a compact SLM as a drop-in replacement of the source model. We apply PRISM to three LLM-enabled planners for mapping and exploration, manipulation, and household assistance, and we demonstrate that PRISM
improves the performance of Llama-3.2-3B from 10-20% of GPT-4o’s performance to over 93% — using only synthetic data. We further demonstrate that the distilled planners generalize across heterogeneous robotic platforms (ground and aerial) and diverse environments (indoor and outdoor). We release all software, trained models, and datasets at zacravichandran.github.io/PRISM.