Uploaded April 2019 | Updated November 2026, 1 hour ago
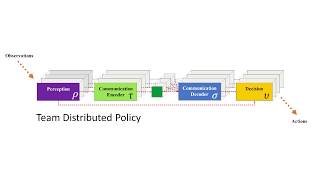
Effective communication is required for teams of robots to solve sophisticated collaborative tasks. In practice it is typical for both the encoding and semantics of communication to be manually defined by an expert; this is true regardless of whether the behaviors themselves are bespoke, optimization based, or learned. We present an agent architecture and training methodology using neural networks to learn task-oriented communication semantics based on the example of a communication-unaware expert policy. A perimeter defense game illustrates the system’s ability to handle dynamically changing numbers of agents and its graceful degradation in performance as communication constraints are tightened or the expert’s observability assumptions are broken.
More details can be found in the article by James Paulos, Steven W. Chen, Daigo Shishika, and Vijay Kumar from the GRASP lab at the University of Pennsylvania.
arxiv.org/abs/1901.08490
Effective communication is required for teams of robots to solve sophisticated collaborative tasks. In practice it is typical for both the encoding and semantics of communication to be manually defined by an expert; this is true regardless of whether the behaviors themselves are bespoke, optimization based, or learned. We present an agent architecture and training methodology using neural networks to learn task-oriented communication semantics based on the example of a communication-unaware expert policy. A perimeter defense game illustrates the system’s ability to handle dynamically changing numbers of agents and its graceful degradation in performance as communication constraints are tightened or the expert’s observability assumptions are broken.
More details can be found in the article by James Paulos, Steven W. Chen, Daigo Shishika, and Vijay Kumar from the GRASP lab at the University of Pennsylvania.
arxiv.org/abs/1901.08490