Towards Fully Autonomous Visual Inspection of Dark Featureless Dam Penstocks using MAVs @KumarLabPenn
Towards Fully Autonomous Visual Inspection of Dark Featureless Dam Penstocks using MAVs  @KumarLabPenn
Uploaded March 2016 | Updated November 2026, 4 days ago
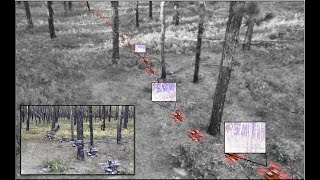
This video shows experiments and results of our work submitted to IROS 2016 on inspection of critical infrastructure lacking geometric features and illumination such as penstocks.

You can reach the related paperwork @ ieeexplore.ieee.org/document/7759734
Towards Fully Autonomous Visual Inspection of Dark Featureless Dam Penstocks using MAVsCooperative Transportation using Small Quadrotors using Monocular Vision and Inertial SensingMonocular Event-Based Vision for Obstacle Avoidance with a QuadrotorDecentralization of Multiagent Policies by Learning What to CommunicateThe Open Vision Computer : An Integrated Sensing and Compute System for Mobile RobotsVision-based Perimeter Defense via Multiview Pose EstimationCoordinate-Free Dynamics and Differential Flatness of a Class of 6DOF Aerial ManipulatorsCPS: Frontier: Collaborative Research: bioCPS for Engineering Living CellsLearning Local Urban Wind Flow Fields From Range SensinghenrikSemi-Dense Visual-Inertial Odometry and Mapping for Quadrotors with SWAP ConstraintsDORA: Divergence-Oriented Data-Relay Algorithm for Partially Connected Robot Teams
Vijay Kumar |

Towards Fully Autonomous Visual Inspection of Dark Featureless Dam Penstocks using MAVs

SHARE TO X SHARE TO REDDIT SHARE TO FACEBOOK WALLPAPER