Uploaded February 2024 | Updated September 2026, 1 week ago
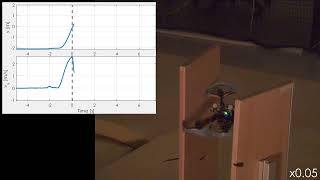
This work presents the design, control and experimental validation of a novel quadrotor that embeds elastic joints in its arms thus paving the road towards the further utilization of soft, squeezable and resiliently collision-tolerant aerial robots. The system design is presented in detail and the properties of the elastic joints are identified. Furthermore, the effects of soft joints into the motion dynamics are outlined, while a Sliding Mode Controller is derived based on a rigid vehicle model. Exploiting the robust control performance of such a controller, accurate trajectory tracking within agile maneuvering is experimentally achieved for the proposed flexible aerial robot. Additional experiments also assess the collision-tolerance of the robot in forcible impacts and the capacity of the closed-loop controller to return the vehicle safely back to hover. Finally, the ability of the system to passively morph its shape and thus squeeze to fit through openings that are smaller than its nominal dimension is demonstrated.
This work presents the design, control and experimental validation of a novel quadrotor that embeds elastic joints in its arms thus paving the road towards the further utilization of soft, squeezable and resiliently collision-tolerant aerial robots. The system design is presented in detail and the properties of the elastic joints are identified. Furthermore, the effects of soft joints into the motion dynamics are outlined, while a Sliding Mode Controller is derived based on a rigid vehicle model. Exploiting the robust control performance of such a controller, accurate trajectory tracking within agile maneuvering is experimentally achieved for the proposed flexible aerial robot. Additional experiments also assess the collision-tolerance of the robot in forcible impacts and the capacity of the closed-loop controller to return the vehicle safely back to hover. Finally, the ability of the system to passively morph its shape and thus squeeze to fit through openings that are smaller than its nominal dimension is demonstrated.