Uploaded May 2018 | Updated September 2026, 2 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Tue AM Pod O.5
Authors: Wang, Chen; Ji, Tete; Nguyen, Thien-Minh; Xie, Lihua
Title: Correlation Flow: Robust Optical Flow Using Kernel Cross-Correlators
Abstract:
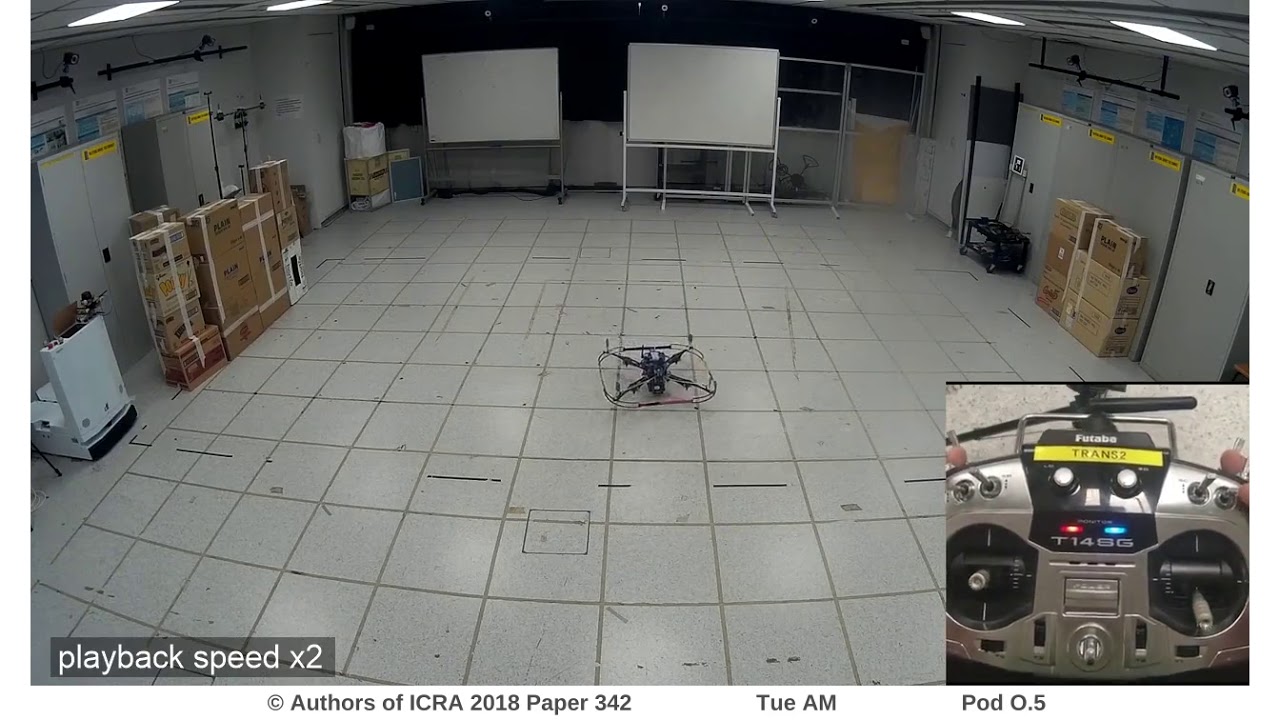
Robust velocity and position estimation is crucial for autonomous robot navigation. The optical flow based methods for autonomous navigation have been receiving increasing attentions in tandem with the development of micro unmanned aerial vehicles. This paper proposes a kernel cross-correlator (KCC) based algorithm to determine optical flow using a monocular camera, which is named as correlation flow (CF). Correlation flow is able to provide reliable and accurate velocity estimation and is robust to motion blur. In addition, it can also estimate the altitude velocity and yaw rate, which are not available by traditional methods. Autonomous flight tests on a quadcopter show that correlation flow can provide robust trajectory estimation with very low processing power. The source codes are released based on the ROS framework.
ICRA 2018 Spotlight Video
Interactive Session Tue AM Pod O.5
Authors: Wang, Chen; Ji, Tete; Nguyen, Thien-Minh; Xie, Lihua
Title: Correlation Flow: Robust Optical Flow Using Kernel Cross-Correlators
Abstract:
Robust velocity and position estimation is crucial for autonomous robot navigation. The optical flow based methods for autonomous navigation have been receiving increasing attentions in tandem with the development of micro unmanned aerial vehicles. This paper proposes a kernel cross-correlator (KCC) based algorithm to determine optical flow using a monocular camera, which is named as correlation flow (CF). Correlation flow is able to provide reliable and accurate velocity estimation and is robust to motion blur. In addition, it can also estimate the altitude velocity and yaw rate, which are not available by traditional methods. Autonomous flight tests on a quadcopter show that correlation flow can provide robust trajectory estimation with very low processing power. The source codes are released based on the ROS framework.