Uploaded May 2026 | Updated November 2026, 2 days ago
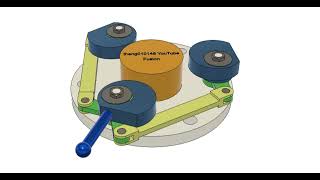
Input: two identical pink screws rotating independently of each other.
The blue sliders and two green rods slide along the two brown rods of the base.
The yellow table slides along the green rods.
The yellow table also slides in the runway of the orange nuts that move on the pink screws. The angle between the nut axis and the runway direction is 45 degrees.
- The table moves along the Y-axis when both screws rotate in the same direction and at the same speed.
Table displacement along the Y-axis: Sy = Ny*L
Ny: number of revolutions of both screws.
- The table moves along the X-axis when the screws rotate in opposite directions at the same speed.
Table displacement along the X-axis: Sx = Nx*L
Nx: number of revolutions of both screws.
Advantage of this mechanism:
- Motion sources are grounded
- Potentially high precision and stiffness are achievable because all joints are of the lower class.
Disadvantage: the kinematic calculations for this mechanism are intricate.
The displacement along the X or Y axis of the table depends on the rotation of both inputs.
This video is based on the video:
youtu.be/6A43NzhUB2c
Inventor files of this video:
mediafire.com/file/a5oxqfdgwea1hmq/Controlling2LinearMotions1Inv.zip/file
STEP files of this video are not available.
Input: two identical pink screws rotating independently of each other.
The blue sliders and two green rods slide along the two brown rods of the base.
The yellow table slides along the green rods.
The yellow table also slides in the runway of the orange nuts that move on the pink screws. The angle between the nut axis and the runway direction is 45 degrees.
- The table moves along the Y-axis when both screws rotate in the same direction and at the same speed.
Table displacement along the Y-axis: Sy = Ny*L
Ny: number of revolutions of both screws.
- The table moves along the X-axis when the screws rotate in opposite directions at the same speed.
Table displacement along the X-axis: Sx = Nx*L
Nx: number of revolutions of both screws.
Advantage of this mechanism:
- Motion sources are grounded
- Potentially high precision and stiffness are achievable because all joints are of the lower class.
Disadvantage: the kinematic calculations for this mechanism are intricate.
The displacement along the X or Y axis of the table depends on the rotation of both inputs.
This video is based on the video:
youtu.be/6A43NzhUB2c
Inventor files of this video:
mediafire.com/file/a5oxqfdgwea1hmq/Controlling2LinearMotions1Inv.zip/file
STEP files of this video are not available.