Uploaded November 2019 | Updated September 2026, 3 weeks ago
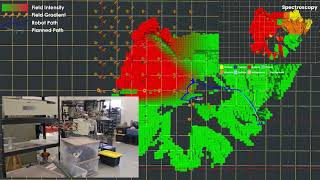
In this experiment we present the autonomous exploration of a building with narrow corridors using an aerial robot. The robot utilizes a multi-modal, LiDAR-visual-inertial, localization and mapping approach that allows it to resiliently estimate its pose despite the lack of geometric structure. To facilitate autonomous exploration the robot further builds in real-time an occupancy map which is then exploited by a graph-based exploration path planner to safely guide the platform towards directions of maximum information gain. The presented experiment took place at the Arts Building of the University of Nevada, Reno.
Relevant papers:
T. Dang, F. Mascarich, S. Khattak, C. Papachristos, K. Alexis, "Graph-based Path Planning for Autonomous Robotic Exploration in Subterranean Environments", IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2019, Macau, China
T. Dang, F. Mascarich, S. Khattak, H. Nguyen, N. Khedekar, C. Papachristos, and K. Alexis, "Field-hardened Robotic Autonomy for Subterranean Exploration", Conference on Field and Service Robotics (FSR), 2019, Aug. 29-31, Tokyo, Japan
In this experiment we present the autonomous exploration of a building with narrow corridors using an aerial robot. The robot utilizes a multi-modal, LiDAR-visual-inertial, localization and mapping approach that allows it to resiliently estimate its pose despite the lack of geometric structure. To facilitate autonomous exploration the robot further builds in real-time an occupancy map which is then exploited by a graph-based exploration path planner to safely guide the platform towards directions of maximum information gain. The presented experiment took place at the Arts Building of the University of Nevada, Reno.
Relevant papers:
T. Dang, F. Mascarich, S. Khattak, C. Papachristos, K. Alexis, "Graph-based Path Planning for Autonomous Robotic Exploration in Subterranean Environments", IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2019, Macau, China
T. Dang, F. Mascarich, S. Khattak, H. Nguyen, N. Khedekar, C. Papachristos, and K. Alexis, "Field-hardened Robotic Autonomy for Subterranean Exploration", Conference on Field and Service Robotics (FSR), 2019, Aug. 29-31, Tokyo, Japan