Uploaded October 2023 | Updated September 2026, 3 weeks ago
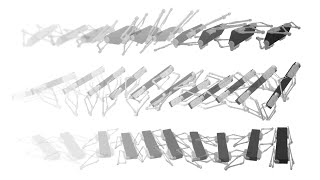
Exploration of new planetary environments necessitates the development of novel concepts of locomotion capable of overcoming the potential challenges present on their surface or even in large-scale subsurface voids such as lava tubes. Planets such as Mars present terrain geometries - both on the surface and underground - that may involve steep and tall obstacles or wide but sharp ditches. Walking robots have recently attracted significant attention owing to their unique ability to conquer perilous terrain as compared to wheeled or tracked systems. However, walking alone may not suffice against such challenging terrain profiles. Simultaneously, autonomous navigation over the largely unknown worlds of other planets can often benefit from high vantage points to acquire informative sensor data and thus better plan future steps. Responding to this need, this work concentrates on the core technologies necessary for developing an autonomous jumping quadruped tailored to having the ability to jump for multiple meters high and thus being able to efficiently overcome major obstacles while also being able to benefit from "bird's eye views" to plan its path ahead. The focus is especially on planets with reduced gravity such as Mars. Within this broader scope, this work introduces the design of a quadruped capable of high jumping and thus short-period flight and specifically contributes the design, implementation, and simulation-based testing of a hierarchical controller for a legged robot that facilitates control of its attitude during its flight phase. The proposed flight controller for quadruped systems utilizes model predictive control principles to manipulate leg actuators and generate appropriate torques to achieve the desired attitude setpoint mid-flight during a jump. The controller is implemented in simulation and tested on a high-fidelity quadruped model considering both the kinematics and dynamics of the platform, as well as the dynamics of the motors.
Exploration of new planetary environments necessitates the development of novel concepts of locomotion capable of overcoming the potential challenges present on their surface or even in large-scale subsurface voids such as lava tubes. Planets such as Mars present terrain geometries - both on the surface and underground - that may involve steep and tall obstacles or wide but sharp ditches. Walking robots have recently attracted significant attention owing to their unique ability to conquer perilous terrain as compared to wheeled or tracked systems. However, walking alone may not suffice against such challenging terrain profiles. Simultaneously, autonomous navigation over the largely unknown worlds of other planets can often benefit from high vantage points to acquire informative sensor data and thus better plan future steps. Responding to this need, this work concentrates on the core technologies necessary for developing an autonomous jumping quadruped tailored to having the ability to jump for multiple meters high and thus being able to efficiently overcome major obstacles while also being able to benefit from "bird's eye views" to plan its path ahead. The focus is especially on planets with reduced gravity such as Mars. Within this broader scope, this work introduces the design of a quadruped capable of high jumping and thus short-period flight and specifically contributes the design, implementation, and simulation-based testing of a hierarchical controller for a legged robot that facilitates control of its attitude during its flight phase. The proposed flight controller for quadruped systems utilizes model predictive control principles to manipulate leg actuators and generate appropriate torques to achieve the desired attitude setpoint mid-flight during a jump. The controller is implemented in simulation and tested on a high-fidelity quadruped model considering both the kinematics and dynamics of the platform, as well as the dynamics of the motors.