Uploaded March 2022 | Updated November 2026, 13 hours ago
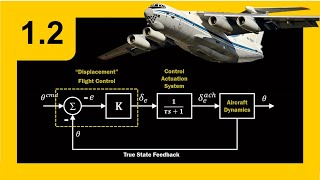
In this module, the optimal control for a linearized engagement with a constant accelerating target is analytically determined by solving the finite horizon linear quadratic regulator. In the limit of intercept effort, augmented proportional navigation obtained. Zero effort miss for an accelerating target is derived and the ZEM form of augmented PN is shown to be similar to true PN.
In this module, the optimal control for a linearized engagement with a constant accelerating target is analytically determined by solving the finite horizon linear quadratic regulator. In the limit of intercept effort, augmented proportional navigation obtained. Zero effort miss for an accelerating target is derived and the ZEM form of augmented PN is shown to be similar to true PN.